
Industrial Automation and Robotics education is not really about machines replacing people; it is about people learning how to make machines behave—reliably, safely, and usefully—inside messy real-world systems. This diagram shows that training as a disciplined conversion process. The inputs bring in what students must work with: technical resources that explain sensors, actuators, control logic, and networks, and industry needs that remind everyone why timing, uptime, and safety matter. The controls—curriculum structures and assessment criteria—act like a blueprint and a referee at the same time: they ensure learning follows a coherent progression and that competence is proven, not assumed. In the central function, students learn to think in sequences and feedback: how a robot “decides,” how a line “responds,” how faults “announce themselves,” and how code becomes motion. The mechanisms—robotic equipment and programming tools—anchor everything to reality, where a miswired signal, a poorly tuned loop, or an unsafe path is instantly visible. The outputs, therefore, are not just trained students, but learners with hands-on confidence: able to program, troubleshoot, and improve automated systems with the calm precision that modern factories and smart facilities demand.
- Manipulator Kinematics & Rigid Body Dynamics: Forward/inverse kinematics via Denavit-Hartenberg (D-H) matrices, Jacobian singularity analysis, and torque-space actuator dynamics.
- Deterministic Control & Shopfloor Execution: Discrete-event state machines, PLC cyclic execution scanning, industrial fieldbuses, and Overall Equipment Effectiveness (\(\text{OEE}\)) optimization.
- AI-Driven & Adaptive Control Paradigms: Integration of Physics-Informed Neural Networks (PINNs), Deep Reinforcement Learning (DRL) for trajectory planning, edge digital twins, and admittance-controlled collaborative robots (cobots).
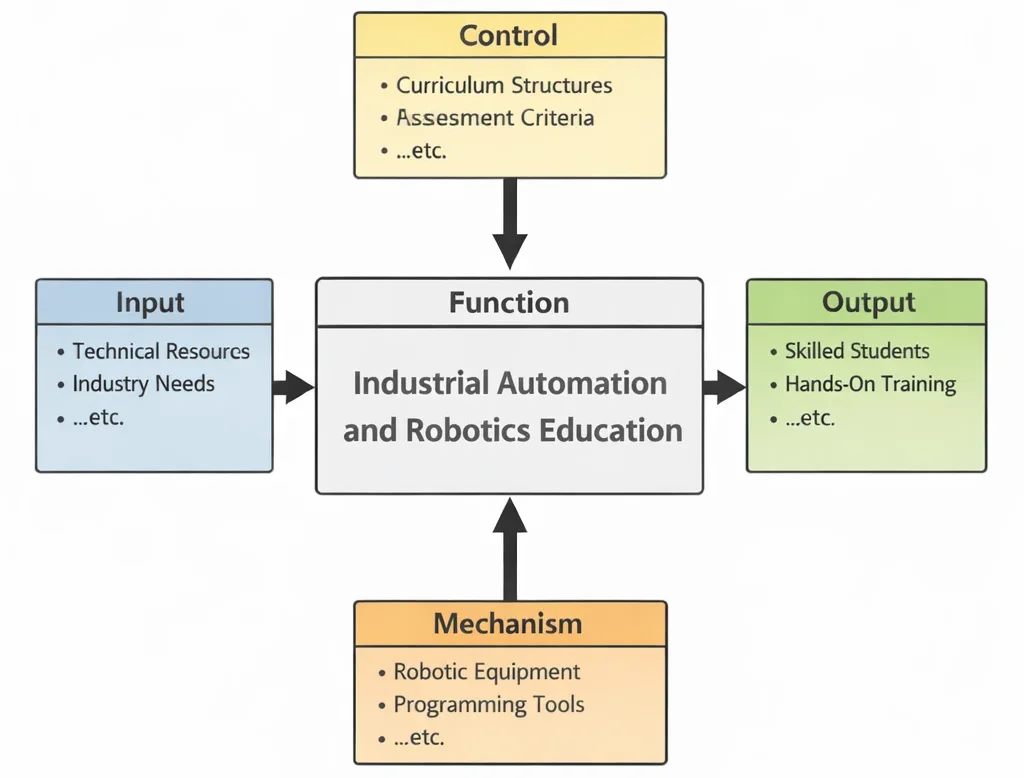
This IDEF0 (Input–Control–Output–Mechanism) diagram presents Industrial Automation and Robotics Education as a structured training process. Inputs on the left—technical resources and industry needs—provide foundational knowledge and real-world requirements. Controls at the top—curriculum structures and assessment criteria—define scope, sequencing, and the standards used to evaluate competence. The central function, Industrial Automation and Robotics Education, transforms those inputs and constraints into organized learning and applied practice. Outputs on the right—skilled students and hands-on training—represent the intended results, emphasizing real operational capability rather than theory alone. Mechanisms at the bottom—robotic equipment and programming tools—provide the practical infrastructure that makes automation concepts testable, programmable, and observable through experiments, labs, and projects.
Industrial automation and robotics have revolutionized how modern factories operate, transforming traditional manufacturing into highly responsive, efficient, and intelligent systems. This field sits at the heart of Industrial and Manufacturing Technologies, blending mechanical precision with advanced computing to enhance productivity, consistency, and adaptability. From robotic arms in automotive assembly lines to fully automated warehouse logistics, automation reduces human error and labor costs while enabling new levels of scalability.
The integration of robotics with Computer-Integrated Manufacturing (CIM) enables seamless coordination of machines and systems across production floors. In parallel, innovations in Digital Twin Technology allow virtual replicas of production environments to be tested and optimized before real-world implementation. This synergy is core to realizing the full potential of Smart Manufacturing and Industry 4.0.
Advanced materials are also reshaping the scope of robotic design. The use of lightweight composites and responsive smart materials—explored further in Advanced Materials and Manufacturing Technologies—enhances robotic agility and energy efficiency. Complementing this, Energy and Resource Efficiency in Manufacturing aligns automation with sustainability goals, reducing operational costs and environmental impacts.
Automation is not limited to hardware; intelligent systems benefit from ergonomic design and human interaction analysis, as explored in Human Factors and Ergonomics in Manufacturing. Moreover, as factories adopt practices from Lean Manufacturing, automation helps eliminate waste and increase flexibility. These improvements extend to areas like Manufacturing Quality Control and Assurance, where sensor-driven systems enable real-time defect detection and process correction.
The importance of automation extends into the broader industrial ecosystem. Enhanced coordination is critical in Supply Chain Management, where robots streamline logistics and inventory tracking. Similarly, a commitment to Sustainable Manufacturing is reinforced through automated monitoring and precision resource allocation. Even niche areas like Additive Manufacturing (3D Printing) gain efficiency when integrated with robotic platforms that handle part removal, inspection, or post-processing.
Industrial automation intersects strongly with foundational engineering disciplines. In Mechanical Engineering, students explore actuators, gear systems, and kinematics essential to robot movement. Specialized applications, such as Automotive Engineering and Biomechanical Engineering, further demonstrate how robotics serve diverse fields—from driverless vehicles to rehabilitation devices.
Robotic control logic builds upon principles taught in Control Systems in Mech Engineering and is often realized in simulations via Mechanical Design and CAD software. These tools are critical for refining performance and ensuring coordination between hardware and software. Physical insights from Fluid Mechanics and Hydraulics, Thermodynamics and Heat Transfer, and Solid Mechanics inform design constraints, thermal regulation, and actuator performance.
Looking ahead, students exploring Robotics and Automation in Mech Eng and related fields will continue to push the boundaries of intelligent, human-aware, and sustainable automation. The blend of cyber-physical systems, real-time data, and adaptive machinery makes industrial automation one of the most transformative and interdisciplinary domains in engineering education today.
Automated Production: Machines, Control, and Intelligent Execution
Navigate through the core topics of Industrial & Manufacturing Technologies to see how industrial automation and robotics interacts across different manufacturing domains:
Industrial & Manufacturing Technologies Overview
Positions automation as a core driver of modern industrial efficiency and serves as the strategic hub for physical technologies.
Industrial Automation & Robotics (Current Module)
Uses robotic systems and automated controls to execute high-speed production tasks with repeatable precision and consistency.
Smart Manufacturing
Integrates robotic hardware with real-time IoT data analytics and cloud networks for self-optimizing adaptive production systems.
Computer-Integrated Manufacturing
Coordinates discrete automated cells, PLCs, and robotic workcells across unified enterprise production environments.
Process Design
Defines operational sequences and physical tooling layouts structured specifically to be effectively automated by robotic manipulators.
Quality Control
Enhances defect detection and dimensional consistency using precise vision-guided automated inspection systems.
Lean Manufacturing
Supports continuous waste elimination and minimizes cycle times through targeted robotic cell efficiency improvements.
Digital Twin Technology
Simulates kinematics, robotic collision risks, and trajectory execution virtually prior to shopfloor deployment.
Additive Manufacturing
Integrates robotic end-effectors for multi-axis 3D printing, automated part removal, and post-processing tasks.
Advanced Materials
Enables specialized robotic gripping, thermal layup, and precise machining of advanced composite components.
Supply Chain Management
Automates warehouse logistics, palletizing, and intra-facility transport using AMRs and automated guided vehicles.
Sustainable Manufacturing
Leverages precision robotic motion and eco-friendly control routines to minimize scrap generation and environmental footprint.
Energy Efficiency
Optimizes motor power draw and braking energy regeneration through intelligent PLC drive parameters and scheduling.
Human Factors
Ensures safe physical and cognitive co-existence between human operators and collaborative robots (cobots).
Core Concepts of Industrial Automation and Robotics
Industrial Automation
Definition: Industrial automation refers to the implementation of control systems such as computers, programmable logic controllers (PLCs), and information technologies to manage industrial processes and machinery. It aims to replace human intervention with automated solutions to increase reliability, consistency, safety, and productivity while minimizing costs and human error. This involves the orchestration of mechanical, electrical, and digital components to create a self-regulating and adaptive manufacturing environment. Industrial automation is foundational to Industry 4.0 and supports the transition from traditional manual operations to smart, interconnected production lines.
Types of Automation:
- Fixed Automation: Also known as hard automation, this is engineered for high-volume, continuous production where the equipment configuration is dedicated to a specific set of operations. Once established, the system has limited flexibility and is typically utilized for mass production of standardized products.
Example: Transfer lines and conveyor systems in automotive engine blocks where each station performs designated machining, drilling, or pressing operations with minimal variability. - Programmable Automation: Characterized by the capability to alter the operational sequence or system geometry via software reprogramming, making it well-suited for batch production or periodic model changeovers. While cycle times are typically longer than fixed automation, it provides high versatility.
Example: Computer Numerical Control (CNC) machining centers programmed via G-code to mill distinct geometries across different production batches. - Flexible Automation: Systems designed for dynamic adaptation to multiple part varieties with negligible downtime for physical retooling or reprogramming. Flexible manufacturing systems (FMS) blend computer-integrated scheduling, automated material handling, and multi-axis articulated robots.
Example: Robotic welding lines equipped with 3D vision systems and automatic tool changers that dynamically adjust weld paths to accommodate mixed-model vehicle chassis on the same line.
Robotics in Industry
Definition: Industrial robotics encompasses the engineering, kinematics, and software control of multi-axis programmable manipulators designed to execute repetitive, hazardous, or high-precision tasks across industrial environments. Industrial robots form the execution core of smart factories across automotive, electronics, medical, and aerospace sectors.
Key Components of Robots
- Manipulators: Mechanical arm assemblies comprising serial or parallel kinematic chains of rigid links interconnected by revolute or prismatic joints. Actuated via high-torque brushless AC servomotors coupled to harmonic drive or cycloidal zero-backlash gearboxes, manipulators provide 4 to 7 degrees of freedom (\(\text{DoF}\)) to position and orient the tool tip within a specified spatial envelope.
- End Effectors: Functional tooling interfaces attached to the mechanical wrist mounting flange. Designs range from pneumatic parallel-jaw and vacuum suction arrays to high-frequency electric spindles, arc welding torches, fiber laser cutting heads, and compliant soft-robotic grippers equipped with multi-axis force-torque transducers.
- Sensors: Internal proprioceptive sensors (optical absolute encoders, resolvers, Hall-effect current sensors) track joint positions, velocities, and motor torques. Exteroceptive sensors (structured-light 3D vision systems, LiDAR, ultrasonic rangefinders, 6-axis wrist load cells) provide situational awareness for obstacle avoidance, bin-picking, and seam tracking.
- Control Systems: The computational architecture comprising real-time industrial PCs running deterministic operating systems (e.g., VxWorks, RT-Linux). Controllers execute trajectory interpolation, forward and inverse kinematics, coordinate transformations, loop closure (PID, feedforward torque control), and safety-rated emergency monitoring adhering to ISO 10218 standards.
- Power Supply & Servo Amplifiers: Solid-state power electronic converters translating 400/480V three-phase AC mains into regulated DC bus voltages, driving pulse-width modulated (PWM) inverter bridges that deliver precision current vectors to each joint servo motor. Systems frequently incorporate regenerative braking resistors or active front-end bus feedback to recover kinetic energy during deceleration.
Contemporary Computational Paradigms in Robotics & Industrial Control
Modern industrial robotics has transitioned beyond rigid pre-programmed teach-pendant routines into continuous, adaptive cyber-physical computation. By integrating mathematical kinematics with machine learning operators and edge hardware, automated systems handle unstructured environments with real-time determinism.
Forward & Inverse Kinematics via Denavit-Hartenberg (D-H) Formulations
The spatial pose (position and orientation) of an \(n\)-axis serial manipulator end-effector relative to the base coordinate frame is determined by concatenating homogeneous transformation matrices \(\mathbf{T}_i^{i-1}\):
$$\mathbf{T}_n^0 = \prod_{i=1}^n \mathbf{A}_i = \mathbf{A}_1 \mathbf{A}_2 \cdots \mathbf{A}_n = \begin{bmatrix} \mathbf{R}_{3 \times 3} & \mathbf{p}_{3 \times 1} \\ \mathbf{0}_{1 \times 3} & 1 \end{bmatrix}$$
Where each link transformation is parameterized by the four classical Denavit-Hartenberg parameters (\(\theta_i, d_i, a_i, \alpha_i\)):
$$\mathbf{A}_i = \begin{bmatrix} \cos\theta_i & -\sin\theta_i\cos\alpha_i & \sin\theta_i\sin\alpha_i & a_i\cos\theta_i \\ \sin\theta_i & \cos\theta_i\cos\alpha_i & -\cos\theta_i\sin\alpha_i & a_i\sin\theta_i \\ 0 & \sin\alpha_i & \cos\alpha_i & d_i \\ 0 & 0 & 0 & 1 \end{bmatrix}$$
The differential relationship between joint velocities \(\dot{\mathbf{q}}\) and operational Cartesian end-effector velocities \(\mathbf{v} = [\dot{\mathbf{p}}^T, \boldsymbol{\omega}^T]^T\) is mapped via the geometric Jacobian matrix: \(\mathbf{v} = \mathbf{J}(\mathbf{q})\dot{\mathbf{q}}\). At kinematic singularities (\(\det(\mathbf{J}) = 0\)), the manipulator loses one or more degrees of freedom, requiring singularity-robust damped least-squares inversion: \(\mathbf{J}^* = \mathbf{J}^T (\mathbf{J}\mathbf{J}^T + \lambda^2 \mathbf{I})^{-1}\).
Physics-Informed Neural Networks (PINNs) & Deep Reinforcement Learning in Motion Control
Traditional rigid-body dynamics computed via the recursive Newton-Euler formulation (\(\mathbf{M}(\mathbf{q})\ddot{\mathbf{q}} + \mathbf{C}(\mathbf{q}, \dot{\mathbf{q}})\dot{\mathbf{q}} + \mathbf{g}(\mathbf{q}) = \boldsymbol{\tau}\)) degrade when dealing with cable-harness viscoelasticity, nonlinear gearbox friction, and varying payloads. Modern architectures embed these governing equations directly into Physics-Informed Neural Networks (PINNs), penalizing deviations from momentum balance:
$$\mathcal{L}_{\text{PINN}} = \|\boldsymbol{\tau}_{\text{meas}} - \hat{\boldsymbol{\tau}}\|^2 + \gamma \|\hat{\mathbf{M}}(\mathbf{q})\ddot{\mathbf{q}} + \hat{\mathbf{C}}(\mathbf{q}, \dot{\mathbf{q}})\dot{\mathbf{q}} + \hat{\mathbf{g}}(\mathbf{q}) - \hat{\boldsymbol{\tau}}\|^2$$
Concurrently, Deep Reinforcement Learning (DRL) agents utilizing soft actor-critic (SAC) algorithms train in high-speed GPU-accelerated physics simulators (e.g., Isaac Sim) to learn generalized bin-picking trajectories. Once zero-shot domain randomization is applied to surface friction and lighting, policies execute inference directly on shopfloor edge TPUs within \(\lt 5\,\text{ms}\) cycle limits.
Systems Engineering Trade-Off Matrix: Industrial Automation Architectures
Deploying automated manufacturing cells requires balancing mechanical speed, capital outlay, software maintainability, and human safety:
| Automation Strategy | Core Performance Advantage | Engineering Bottlenecks & Failure Modes | System Compromise & Design Mitigation |
|---|---|---|---|
| Hard / Fixed Cam-Driven Automation | Extremely high cycle rates (\(\gt 150\,\text{parts/min}\)); unmatched mechanical repeatability and low unit cost at scale. | Zero kinematic flexibility; catastrophic retooling costs and extensive downtime during product redesign. | Strictly viable for mature products with multi-million unit lifecycles (e.g., standard fasteners, consumer syringes). |
| 6-Axis Articulated Industrial Robots | Full 3D spherical reach envelope; high payload-to-weight ratio (\(\gt 100\,\text{kg}\)); high path velocity (\(\gt 2\,\text{m/s}\)). | Mandates physical safety interlocked perimeter caging; complex singularity management near axis alignments. | Consumes significant factory floorspace; requires dedicated robotic safety PLCs and light curtain mute zones. |
| Collaborative Robots (Cobots) | Fenceless deployment alongside human technicians; intuitive hand-guiding lead-through programming. | Severely limited operating velocities (\(v_{\text{tool}} \le 250\,\text{mm/s}\) under ISO/TS 15066); low payloads (\(\le 20\,\text{kg}\)). | Integrate dual-mode operation: full speed when area scanners confirm operator absence, switching to collaborative mode upon entry. |
| Autonomous Mobile Robots (AMRs) | Infrastructure-free navigation via LiDAR SLAM; dynamically navigates around facility obstacles without fixed magnetic tracks. | Localization loss in symmetric aisles; Wi-Fi network dead-zones interrupting supervisory fleet commands. | Deploy ceiling visual fiducials (AprilTags) for secondary localization; integrate industrial private 5G mesh networks. |
Integration of AI, Edge Computing, and Machine Learning
AI in Industrial Automation
Role of AI: Artificial Intelligence has become a cornerstone of modern industrial automation, revolutionizing how factories operate by mimicking cognitive functions such as learning, reasoning, and problem-solving. By embedding AI into control systems, manufacturers achieve high levels of operational efficiency, accuracy, and adaptability.
AI algorithms analyze historical and real-time telemetry to detect anomalies, predict equipment failures, optimize scheduling, and maximize throughput. These systems enable machines to make context-aware decisions without manual intervention, leading to resilient operations and reduced downtime.
Core Industrial Applications:
- Predictive Maintenance: AI models evaluate multi-axis vibration accelerometer spectra and motor current signature analysis (MCSA) to forecast bearing spalling and gear wear thousands of operational cycles before catastrophic seizure occurs.
- Quality Control: Convolutional neural networks (CNNs) mounted on high-speed lines classify surface blemishes, micro-cracks, and incomplete weld seams at line velocities exceeding \(60\,\text{m/min}\).
- Production Scheduling: Dynamic solvers resolve NP-hard job-shop scheduling problems, re-routing material flows in real time around offline cells or tooling changes.
- Inventory Optimization: Machine learning balances raw stock buffers against production pull signals, preventing WIP (Work In Progress) pileups and reducing inventory holding costs.
Machine Learning for Adaptive Systems
Definition: Machine Learning (ML) encompasses statistical algorithms that optimize operational parameters autonomously through data exposure, establishing empirical mappings without explicit procedural programming.
Applications:
- Real-Time Process Optimization: Self-tuning control algorithms dynamically adjust feed rates and spindle speeds on CNC machines to eliminate chatter vibrations.
- Adaptive Motion Control: Real-time neural networks adjust feedforward inertia models to compensate for variable tool payload mass.
- Automated Fault Diagnosis: Clustering algorithms group subtle electrical transients on servo buses to isolate impending drive inverter failures.
Edge Computing and the Industrial Internet of Things (IIoT)
Edge Computing Architecture: Moving analytical computation directly to industrial IPCs and embedded FPGA accelerators situated at the machine cell eliminates cloud latency (\(\tau_{\text{cloud}} \approx 50\text{--}200\,\text{ms}\) vs. \(\tau_{\text{edge}} \lt 2\,\text{ms}\)). This deterministic response speed is vital for closed-loop motion aborts and safety-critical vision inspection.
Industrial IoT Integration: The IIoT interconnects smart sensors, valves, drives, and controllers across open communication architectures such as OPC Unified Architecture (OPC-UA) and MQTT over Time-Sensitive Networking (TSN). This standardizes data access, linking plant-floor telemetry seamlessly to enterprise cloud historians.
Applications Across Industrial Sectors
Manufacturing and Production
Automated assembly cells combine multi-axis robots with smart feeders to perform screwdriving, adhesive dispensing, and riveting with sub-millimeter precision. AGVs and AMRs transport work-in-progress pallets between production nodes, while automated additive manufacturing cells run continuous lights-out production with robotic build plate clearing.
Automotive Industry
Automotive body shops rely on dense clusters of articulated robots executing resistance spot welding and structural laser brazing across car unibody frames. Robotic paint booths utilize high-speed electrostatic bell atomizers to achieve uniform coating thickness while recirculating overspray. Powertrain lines deploy precision robots for engine valve seating and EV battery pack module assembly.
Electronics Manufacturing
High-speed surface-mount technology (SMT) pick-and-place machines place passive components and microprocessors at speeds up to \(100{,}000\,\text{components/hr}\). Downstream, Automated Optical Inspection (AOI) and automated inline flying-probe test fixtures verify solder meniscus geometry and electrical circuit continuity.
Food, Beverage, and Pharmaceuticals
High-speed delta robots equipped with machine vision perform pick-and-place sorting and packaging of delicate bakery items. Pharmaceutical packaging lines enforce strict cGMP cleanroom protocols, deploying robotic isolators to fill, stopper, and seal sterile vaccine vials with zero human intervention.
Aerospace and Defense
Heavy-duty gantry robots perform drilling and countersinking across carbon-fiber composite aircraft wing skins, maintaining tight perpendicularity tolerances over curved aerodynamic contours. Automated tape laying (ATL) and automated fiber placement (AFP) robots manufacture fuselage barrels with optimized structural fiber orientations.
Key Technologies in Industrial Automation and Robotics
Programmable Logic Controllers (PLCs)
PLCs serve as the ruggedized computational foundation of factory automation. Operating on deterministic cyclic scan loops (Input Read \(\rightarrow\) Logic Execution \(\rightarrow\) Output Write), PLCs execute control code written in IEC 61131-3 languages (Ladder Diagram, Structured Text, Function Block Diagram). Redundant CPU architectures provide uninterrupted failover for critical processes.
Sensors and Actuators
Sensors convert physical phenomena into digital or analog engineering units. Inductive, capacitive, and optical sensors track discrete part presence, while IO-Link interfaces allow bidirectional parameterization and health monitoring down to the individual device level. Actuators convert electrical, pneumatic, or hydraulic power into controlled physical motion, utilizing closed-loop feedback encoders to achieve high positional accuracy.
Human-Machine Interfaces (HMIs) & SCADA
HMIs present graphical representations of machine states, alarm summaries, and setpoint controls to shopfloor operators. Supervisory Control and Data Acquisition (SCADA) systems aggregate multi-cell HMI data across the plant, logging historical trends, tracking Overall Equipment Effectiveness (\(\text{OEE}\)), and enforcing recipe management protocols.
Collaborative Robots (Cobots) & Safety Systems
Cobots incorporate internal joint torque sensors that monitor external contact forces, safely stopping motion within milliseconds if force limits (\(F_{\text{limit}} \approx 150\,\text{N}\)) are breached. Integrated safety systems combine safety-rated laser scanners, safety gate interlocks, and emergency stop circuits wired into dual-channel safety relays (Performance Level d/e, ISO 13849-1).
Digital Twin Technology
Digital twins synthesize kinematic 3D CAD assemblies with discrete-event physics engines and virtual PLC emulators. By connecting virtual hardware to physical controllers (Hardware-in-the-Loop, HIL), automation engineers debug entire production cells and cycle time bottlenecks before cutting physical steel.
Applications of Automation in Robotic Systems
About This Interactive Simulator:
This interactive simulator models the operational throughput of an automated manufacturing cell comprising an infeed conveyor, a 6-axis transfer robot, and CNC machining stations. Adjust infeed speed, robotic transfer latency, and the number of active CNC cells to analyze cycle bottlenecks and net line capacity in real time.
- Solid Cyan Line: Automated Net Production Throughput (\(\text{parts/hr}\)) across varying infeed rates.
- Dashed Rose Line: Maximum Theoretical Line Capacity Limit (\(120\,\text{parts/hr}\) threshold).
- Interactive Sliders: Modulate Ingest Speed (\(20\text{--}150\,\text{parts/hr}\)), Robotic Transfer Latency (\(0.5\text{--}5.0\,\text{s}\)), and Active CNC Cells (1–6).
Interactive Robotic Assembly Cell Throughput Simulator
Benefits of Industrial Automation and Robotics
- Increased Productivity: Industrial automation significantly enhances productivity by enabling continuous 24/7 operations without the constraints of human fatigue, shift changes, or labor shortages. Automated systems work at high speeds with minimal downtime, accelerating cycle times and throughput. In industries like semiconductor manufacturing or automotive assembly, automation facilitates parallel processing across distinct workstations, vastly increasing output while predictive scheduling software eliminates idle line starvation.
- Improved Quality: One of the most impactful benefits of robotics is the dramatic improvement in product quality and dimensional consistency. Machines operate with high kinematic precision and sub-millimeter repeatability, minimizing human error. Closed-loop control systems instantaneously correct process deviations, ensuring tolerances are consistently maintained across high-precision electronic and medical device assemblies.
- Cost Reduction: Although initial capital outlays can be substantial, long-term operational savings are significant. Automation lowers direct personnel overhead, eliminates material scrap via precise trajectory dispensing, and synchronizes utility loads with production schedules to reduce energy consumption. Studies show manufacturers can reduce operating costs by up to 30% through strategic automation.
- Enhanced Safety: Automation improves workplace safety by relocating workers away from toxic fumes, extreme temperatures, high voltages, and heavy lifting operations. Machine safeguarding measures—such as safety light curtains, interlocked gates, and cobot force-monitoring arrays—mitigate pinch and collision hazards, drastically cutting workers' compensation claims.
- Scalability: Modern automation architectures are inherently modular and reconfigurable. Manufacturers quickly adapt to product design revisions and demand fluctuations by swapping end-effectors and modifying software parameters, utilizing digital twins to simulate scale-up scenarios prior to physical equipment retooling.
Challenges & Technical Constraints in Implementation
- High Upfront Capital Expenditure & Long Payback Horizons: Procuring articulated robots, high-resolution machine vision, PLCs, safety gates, and specialized end-effectors requires significant capital. Ancillary engineering costs—including mechanical fixturing, custom cell integration, and electrical grid upgrades—frequently exceed equipment purchase prices by a factor of 2 or 3, challenging smaller enterprises.
- Specialized Technical Skill Gaps: Deploying and servicing automated cells demands an interdisciplinary workforce proficient in kinematic path planning, IEC 61131-3 PLC programming, fieldbus diagnostics, and machine learning integration. A lack of trained mechatronics technicians leads to lengthy downtimes when unforeseen system faults occur.
- Operational Technology (OT) Cybersecurity Vulnerabilities: Bridging legacy factory fieldbuses to cloud IIoT platforms introduces severe cyber-physical risks. Insecure industrial network protocols lacking encrypted authentication (e.g., legacy Modbus TCP) leave robotic controllers vulnerable to malicious command injection or ransomware that can halt entire production plants.
- Legacy Hardware Integration & Deterministic Synchronization: Integrating cutting-edge multi-axis cobots with older legacy machine tools lacking digital I/O requires custom middleware and interface boards. Jitter and unsynchronized communication clocks across disparate vendors can cause handshake timeouts and transfer misalignments.
- Ethical Governance & Workforce Transition Management: The introduction of high-throughput robotic cells inevitably disrupts traditional shopfloor labor dynamics. Successful adoption requires proactive workforce reskilling programs that transition manual operators into higher-value automation maintenance, supervisory control, and quality analytics roles.
Emerging Trends in Industrial Automation and Robotics
- Edge AI & Vision-Guided Autonomous Trajectory Generation: Embedded edge processors run neural networks that perceive random, unoriented parts in supply bins, calculating collision-free inverse kinematic grasp paths on the fly without requiring mechanical part feeders.
- Ultra-Low Latency 5G Private Factory Networks: Private 5G networks with Time-Sensitive Networking (TSN) provide the sub-millisecond determinism needed to coordinate fleets of Autonomous Mobile Robots (AMRs) without tethered fieldbus cabling.
- Eco-Friendly Trajectory Planning & Energy Regeneration: Robotic trajectory planners optimize acceleration profiles to minimize instantaneous motor power peaks (\(I^2 R\) losses), while regenerative DC bus capacitors capture kinetic energy during deceleration cycles for reuse across adjacent axes.
- Swarm Intelligence in Fleet Logistics: Autonomous warehouse vehicles leverage decentralized swarm algorithms, dynamically sharing path intentions to eliminate traffic bottlenecks and self-rebalance material distribution across high-volume fulfillment hubs.
- Robotics-as-a-Service (RaaS) Business Models: Subscription-based leasing models allow manufacturers to deploy robotic cells as an operating expense (\(\text{OpEx}\)) rather than a capital investment (\(\text{CapEx}\)), democratizing automation access for small-to-medium manufacturing operations.
Future Directions in Industrial Automation and Robotics
- Hyperautomation & End-to-End Cyber-Physical Synthesis: Unifying physical shopfloor PLCs with enterprise ERP and supplier supply chain software creates self-healing production networks that automatically reorder materials, re-sequence machine batches, and schedule predictive maintenance.
- Zero-Touch & Lights-Out Manufacturing Facilities: Fully enclosed, automated manufacturing facilities operate continuously without human intervention, eliminating ambient lighting and HVAC requirements to drastically cut facility energy consumption.
- Global Industry 4.0 Standard Harmonization: International convergence around open architectures—such as Asset Administration Shells (AAS) and OPC-UA companion specifications—guarantees plug-and-produce interoperability across multi-vendor equipment worldwide.
- Human-Centric Industry 5.0 Workcell Symbiosis: Future manufacturing platforms integrate multimodal biosensors to monitor operator ergonomics and cognitive fatigue, dynamically shifting repetitive tasks to collaborative cobots while preserving human oversight.
- Decentralized Multi-Agent Digital Twins: Interconnected digital twins run physics-based predictive simulations in lockstep with live telematics, autonomously testing alternative process pathways to optimize line throughput before physical changes are made.
Why Study Industrial Automation and Robotics
Transforming Manufacturing Through Automation
Industrial automation and robotics involve using machines and control systems to perform tasks with minimal human intervention. Students learn how automation enhances consistency, speed, and precision in production processes. This transformation supports modern, efficient, and scalable manufacturing.
Design and Integration of Robotic Systems
Students study how to program and integrate robotic arms, conveyor systems, and vision systems. They explore how robots collaborate with machines and humans on factory floors. This knowledge enables flexible and adaptive production.
Control Systems and Programmable Logic Controllers (PLCs)
The course introduces students to sensors, actuators, and PLCs that manage automated systems. They learn to configure logic-based programs to control equipment. This skill is foundational to all industrial automation applications.
Human-Robot Collaboration and Safety
Collaborative robots (cobots) are designed to work safely alongside people. Students learn safety protocols, ergonomics, and interaction design. This prepares them to implement automation in a way that enhances human productivity.
Global Applications and Career Potential
Automation and robotics are transforming industries such as automotive, electronics, food processing, and logistics. Students develop in-demand skills for roles in design, maintenance, and systems integration. This field offers exciting and future-proof careers.
Industrial Automation and Robotics: Conclusion
Industrial automation and robotics represent a transformative force reshaping the landscape of modern manufacturing and industrial processes. These technologies have evolved from simple mechanization into sophisticated systems powered by artificial intelligence, machine learning, and the Internet of Things (IoT). Their impact spans every major industrial sector—from automotive to pharmaceuticals, from electronics to aerospace—bringing about unprecedented improvements in efficiency, precision, and safety.
One of the most significant contributions of industrial automation is its ability to reduce human error and standardize production quality. Robots can perform repetitive tasks with exceptional consistency, allowing human workers to shift their focus toward higher-level problem-solving, system supervision, and innovation. In highly regulated industries, such as healthcare and food processing, the use of robotics ensures strict compliance with hygiene and safety standards, significantly reducing contamination risks.
Furthermore, the integration of AI has given rise to intelligent automation systems that can learn from data, adapt to changing conditions, and make real-time decisions. For instance, AI-powered quality control systems can detect product defects faster than traditional methods, and predictive maintenance algorithms can foresee equipment failures, allowing manufacturers to minimize unplanned downtime. Such advancements are enhancing operational reliability and extending the lifespan of industrial assets.
Equally important is the role of industrial robotics in advancing workplace safety. Robots are now deployed in environments that pose significant hazards to human workers—such as extreme temperatures, toxic atmospheres, or high-speed operations. By taking over these tasks, robotics help reduce injury rates and create safer working environments. In tandem, collaborative robots (cobots) are working side by side with humans, augmenting their capabilities and reducing physical strain.
From a strategic perspective, automation allows organizations to achieve higher throughput without sacrificing product quality. As demand for customized products rises, flexible automation systems enable rapid reconfiguration of production lines, ensuring manufacturers remain agile and responsive. This is especially critical in today's volatile global economy, where adaptability is key to maintaining competitiveness.
Globally, the rise of smart factories and Industry 4.0 has accelerated the adoption of interconnected and data-driven automation systems. Businesses that invest in automation and robotics not only improve productivity but also gain deeper insights into operational performance through data analytics. These insights drive continuous improvement and strategic decision-making.
The convergence of robotics, AI, and IoT is also contributing to sustainability goals by reducing energy consumption, material waste, and carbon emissions. Intelligent systems optimize resource use and help manufacturers implement greener practices, aligning industrial growth with environmental responsibility.
As we look ahead, the role of automation will only expand. With technologies such as 5G connectivity, edge computing, and digital twins on the rise, industrial processes will become increasingly autonomous and intelligent. Robotics-as-a-Service (RaaS) models are also democratizing access to automation, allowing small and medium enterprises (SMEs) to benefit from advanced capabilities without prohibitive costs.
In conclusion, industrial automation and robotics are not merely tools for improving manufacturing—they are foundational pillars for the future of work, production, and technological advancement. Their continued development promises to reshape industries, empower workforces, and drive global innovation, setting the stage for a more efficient, safe, and resilient industrial ecosystem.
Industrial Automation and Robotics: Frequently Asked Questions
This FAQ introduces key ideas, components, and trends in industrial automation and robotics, helping you connect classroom concepts to real manufacturing practice.
1. What is industrial automation and how is it different from traditional manual manufacturing?
2. What is meant by industrial robotics, and how does it relate to industrial automation?
3. Which core components are typically found in an industrial automation system?
4. What are the main benefits of introducing automation and robotics into a manufacturing process?
5. What are common risks or challenges when implementing industrial automation and robotics?
6. What is a collaborative robot (cobot), and how is it used in manufacturing?
7. How does industrial automation connect to concepts such as Industry 4.0 and smart factories?
8. How does automation and robotics affect manufacturing jobs and workforce skills?
9. What steps should a manufacturer follow when planning an industrial automation or robotics project?
10. What future trends are shaping the development of industrial automation and robotics?
Industrial Automation & Robotics Practice Modules
Section 1: Interactive Knowledge Self-Assessment
1. What is the fundamental operational difference between fixed and flexible automation?
2. What are the key hardware components that constitute a complete industrial robot?
3. How does a Programmable Logic Controller (PLC) coordinate shopfloor operations?
4. What physical safety mechanisms differentiate Collaborative Robots (Cobots) from traditional industrial robots?
5. What role does Edge Computing play in high-speed robotic vision systems?
6. How does Digital Twin technology streamline robotic workcell commissioning?
7. What is the business model and advantage of Robotics-as-a-Service (RaaS)?
8. How does hyperautomation differ from conventional task-level automation?
Section 2: Analytical & Scenario-Based Case Studies
1. Scenario: A bottling line experiences high rejection rates due to misaligned caps. How can a machine vision system integrated with a PLC fix this?
2. Scenario: An automotive welding cell suffers intermittent robot stops due to cable harness fatigue at joint 4. What preventative measures should be taken?
3. Scenario: A warehouse uses Autonomous Mobile Robots (AMRs) that frequently stop at intersections due to human congestion. How can fleet coordination be optimized?
4. Scenario: A CNC machine tending cell uses a cobot, but cycle time is 25% too slow. What safety re-configuration allows higher speed?
5. Scenario: A pharmaceutical factory suffers cyber intrusions into its PLC networks. How should OT network architecture be restructured?
6. Scenario: A PCB plant experiences vacuum gripper drops on miniature surface-mount components. How can gripping reliability be resolved?
7. Scenario: A foundry deploying heavy industrial robots suffers frequent joint motor overheating due to thermal radiant heat from molten aluminum casting.
Section 3: Mathematical Biomechanics & Engineering Calculations
Work through these step-by-step mathematical calculations evaluating Overall Equipment Effectiveness (\(\text{OEE}\)), manipulator joint torques, trapezoidal motion profiles, cylinder clamping forces, electrical power draw, and 3D spatial displacements.
Problem 1: Overall Equipment Effectiveness (OEE) of a Robotic Welding Cell
Problem Statement: Calculate the Overall Equipment Effectiveness (\(\text{OEE}\)) of an automated robotic welding cell operating over an \(8\,\text{hour}\) shift (\(480\,\text{min}\)). The shift includes \(30\,\text{min}\) planned maintenance downtime and \(40\,\text{min}\) unplanned breakdowns. The cell produces \(400\) total welded assemblies, of which \(20\) are rejected for weld defects. The ideal nameplate cycle time is \(0.80\,\text{min/assembly}\).
Step 1: Availability (\(A\)) Determination
$$\text{Planned Operating Time} = 480\,\text{min} - 30\,\text{min} = 450\,\text{min}$$
$$\text{Operating Run Time} = 450\,\text{min} - 40\,\text{min} = 410\,\text{min}$$
$$A = \frac{\text{Operating Run Time}}{\text{Planned Operating Time}} = \frac{410}{450} \approx \mathbf{0.9111} \quad (91.11\%)$$
Step 2: Performance (\(P\)) Determination
$$P = \frac{\text{Total Assemblies} \times \text{Ideal Cycle Time}}{\text{Operating Run Time}} = \frac{400 \times 0.80\,\text{min}}{410\,\text{min}} = \frac{320}{410} \approx \mathbf{0.7805} \quad (78.05\%)$$
Step 3: Quality (\(Q\)) Determination
$$Q = \frac{\text{Conforming Assemblies}}{\text{Total Assemblies}} = \frac{400 - 20}{400} = \frac{380}{400} = \mathbf{0.9500} \quad (95.00\%)$$
Step 4: Overall Equipment Effectiveness (\(\text{OEE}\)) Calculation
$$\text{OEE} = A \times P \times Q = 0.9111 \times 0.7805 \times 0.9500 \approx \mathbf{0.6756} \quad (\mathbf{67.56\%})$$
Engineering Interpretation: An \(\text{OEE}\) of \(67.56\%\) indicates that speed losses (\(P = 78.05\%\)) represent the largest operational bottleneck. Root causes such as part feed jitter or unnecessary robot deceleration ramps should be targeted first.
Problem 2: Manipulator Joint Static Torque & Payload Limit Calculation
Problem Statement: A robotic manipulator elbow joint has a maximum continuous rated output torque \(\tau_{\text{max}} = 180.0\,\text{N}\cdot\text{m}\). The horizontal radial distance from the joint pivot to the center of gravity of the payload is \(d = 0.45\,\text{m}\). Assuming static equilibrium in a horizontal arm configuration with gravity \(g = 9.81\,\text{m/s}^2\), calculate the maximum allowable payload mass \(m\).
Step 1: Torque Equilibrium Formulation
$$\tau = F_{\text{grav}} \cdot d = (m \cdot g) \cdot d$$
Step 2: Algebraic Isolation of Mass (\(m\))
$$m = \frac{\tau}{g \cdot d}$$
$$m = \frac{180.0\,\text{N}\cdot\text{m}}{9.81\,\frac{\text{m}}{\text{s}^2} \times 0.45\,\text{m}} = \frac{180.0}{4.4145} \approx \mathbf{40.78\,\text{kg}}$$
Engineering Interpretation: The maximum static payload is \(40.78\,\text{kg}\). In dynamic trajectories, inertial angular accelerations (\(I\ddot{\theta}\)) require derating this nominal static payload by \(30\text{--}50\%\) to avoid motor drive overcurrent trips.
Problem 3: Pick-and-Place Actuator Trapezoidal Velocity Profile
Problem Statement: A linear Cartesian pick-and-place gantry must traverse a displacement \(S = 1.20\,\text{m}\) within a total motion time \(t_{\text{total}} = 0.80\,\text{s}\). The motion follows a symmetric trapezoidal velocity profile with acceleration time \(t_{\text{acc}} = 0.20\,\text{s}\), constant velocity cruising time \(t_{\text{const}} = 0.40\,\text{s}\), and deceleration time \(t_{\text{dec}} = 0.20\,\text{s}\). Determine the peak velocity \(v_{\text{max}}\).
Step 1: Kinematic Distance Integration Formula
$$S = v_{\text{max}} \left( t_{\text{const}} + \frac{1}{2}t_{\text{acc}} + \frac{1}{2}t_{\text{dec}} \right)$$
Step 2: Metric Substitution & Velocity Solution
$$1.20 = v_{\text{max}} \left( 0.40 + 0.5(0.20) + 0.5(0.20) \right)$$
$$1.20 = v_{\text{max}} (0.40 + 0.10 + 0.10) = v_{\text{max}} (0.60)$$
$$v_{\text{max}} = \frac{1.20\,\text{m}}{0.60\,\text{s}} = \mathbf{2.00\,\text{m/s}}$$
Engineering Interpretation: The linear actuator reaches a steady-state cruise velocity of \(2.00\,\text{m/s}\) with an acceleration requirement of \(a = v_{\text{max}} / t_{\text{acc}} = 10.0\,\text{m/s}^2\) (\(\approx 1.02\,g\)), dictating timing belt tension ratings.
Problem 4: Pneumatic Robotic Gripper Clamping Force Calculation
Problem Statement: A double-acting pneumatic gripper cylinder operates at a regulated line pressure \(P = 6.0\,\text{bar}\) (\(600{,}000\,\text{N/m}^2\)). The internal piston bore diameter is \(d = 0.04\,\text{m}\) (\(40\,\text{mm}\)). Calculate the theoretical clamping force \(F_{\text{clamp}}\) generated by the cylinder during forward stroke extension.
Step 1: Piston Effective Cross-Sectional Area
$$A = \pi \left( \frac{d}{2} \right)^2 = \pi (0.02\,\text{m})^2 \approx 3.14159 \times 0.0004 = \mathbf{0.0012566\,\text{m}^2}$$
Step 2: Pneumatic Clamping Force Evaluation
$$F_{\text{clamp}} = P \cdot A = 600{,}000\,\frac{\text{N}}{\text{m}^2} \times 0.0012566\,\text{m}^2 = \mathbf{753.98\,\text{N}} \quad (\mathbf{754.0\,\text{N}})$$
Engineering Interpretation: The cylinder generates \(754.0\,\text{N}\) of thrust. Assuming standard rubber gripper finger pads with a coefficient of friction \(\mu = 0.35\) and a safety factor \(k_s = 2.0\), the safe frictional payload lift capacity is \(m_{\text{lift}} = (\mu \cdot F_{\text{clamp}}) / (k_s \cdot g) \approx 13.45\,\text{kg}\).
Problem 5: Robotic Servo Motor Electrical Power & Thermal Energy Dissipation
Problem Statement: During a high-acceleration vertical lift cycle, an industrial robot joint servo amplifier draws a continuous DC bus current \(I = 25.0\,\text{A}\) at an operating bus potential \(V = 400.0\,\text{V}\). Calculate the total electrical power \(P\) in \(\text{kW}\) and the total electrical energy \(E\) consumed in kilojoules (\(\text{kJ}\)) over a \(15.0\,\text{second}\) sustained move segment.
Step 1: Electrical Power Draw Evaluation
$$P = V \cdot I = 400.0\,\text{V} \times 25.0\,\text{A} = 10{,}000\,\text{W} = \mathbf{10.0\,\text{kW}}$$
Step 2: Total Energy Consumption Integration
$$E = P \cdot t = 10.0\,\text{kW} \times 15.0\,\text{s} = 150.0\,\text{kW}\cdot\text{s} = \mathbf{150.0\,\text{kJ}}$$
Engineering Interpretation: The segment expends \(150.0\,\text{kJ}\). In continuous operation, heat dissipation from motor windings and cabinet servo drives must be extracted via enclosure air conditioners to prevent thermal shutdowns.
Problem 6: Serial Reliability Architecture Analysis of an Automated Workcell
Problem Statement: An automated manufacturing workcell relies on four critical sub-systems configured functionally in series: Main PLC (\(R_1 = 0.995\)), Servo Drive Inverter Rack (\(R_2 = 0.980\)), Pneumatic Gripper Assembly (\(R_3 = 0.970\)), and Machine Vision Inspection System (\(R_4 = 0.990\)). Determine the overall system reliability \(R_{\text{cell}}\).
Step 1: Series Reliability Multiplicative Law
$$R_{\text{cell}} = \prod_{i=1}^4 R_i = R_1 \times R_2 \times R_3 \times R_4$$
Step 2: Sequential State Evaluation
$$R_{\text{cell}} = 0.995 \times 0.980 \times 0.970 \times 0.990$$
$$R_{\text{cell}} = (0.97510) \times (0.96030) \approx \mathbf{0.93638} \quad (\mathbf{93.64\%})$$
Engineering Interpretation: Despite high individual reliability metrics (\(\ge 97\%\)), the cumulative unreliability is \(1 - 0.9364 = 6.36\%\). The pneumatic actuator (\(R_3 = 0.970\)) represents the weakest link, identifying it as the primary candidate for preventative maintenance or redundant parallel valving.
Problem 7: 3D Euclidean Spatial Tool Center Point (TCP) Displacement
Problem Statement: An industrial robot moves its Tool Center Point (TCP) linearly from pick coordinate \(P_1 = (100.0, 200.0, 50.0)\,\text{mm}\) to place coordinate \(P_2 = (400.0, 600.0, 200.0)\,\text{mm}\). Compute the net 3D Euclidean spatial displacement distance \(D\).
Step 1: Coordinate Differential Calculation
$$\Delta X = 400.0 - 100.0 = 300.0\,\text{mm}$$
$$\Delta Y = 600.0 - 200.0 = 400.0\,\text{mm}$$
$$\Delta Z = 200.0 - 50.0 = 150.0\,\text{mm}$$
Step 2: 3D Euclidean Vector Norm Evaluation
$$D = \sqrt{(\Delta X)^2 + (\Delta Y)^2 + (\Delta Z)^2} = \sqrt{(300.0)^2 + (400.0)^2 + (150.0)^2}$$
$$D = \sqrt{90{,}000 + 160{,}000 + 22{,}500} = \sqrt{272{,}500} \approx \mathbf{522.02\,\text{mm}}$$
Engineering Interpretation: The total spatial path length is \(522.02\,\text{mm}\). At a programmed TCP Cartesian velocity \(v = 1.0\,\text{m/s}\) (\(1{,}000\,\text{mm/s}\)), the steady-state transfer time is approximately \(0.522\,\text{seconds}\).