
Traditional robotic systems rely on carefully engineered models and hand-tuned control parameters. Engineers typically derive mathematical models of mechanical dynamics, design controllers using known system properties, and then tune gains to achieve acceptable performance.
Biological systems operate very differently. Animals rarely possess exact models of their bodies or environments. Instead, they adapt through experience and evolutionary processes, gradually improving behavior over time.
Evolutionary and adaptive robotics explore how machines can improve performance through iterative optimization, self-adjustment, and learning mechanisms. Rather than designing every behavior manually, engineers define objective functions and allow algorithms to search for effective solutions within a high-dimensional parameter space.
This approach becomes especially valuable when analytical modeling becomes difficult due to:
- Strong nonlinear coupling between kinematic links and drive parameters
- Discontinuous system responses and impact dynamics
- High-dimensional, unconstrained control action spaces
- Unstructured, partially observable environmental interactions
Instead of computing a single optimal solution analytically, engineers allow populations of candidate controllers to evolve, adapt, or learn. This paradigm forms part of the broader Intelligence and Decision Systems in Robotics cluster together with Reinforcement Learning for Robot Control and Swarm and Multi-Agent Robotics.
Interactive Quick Review: Biological Inspiration & Adaptation
Test your understanding of biological adaptation versus traditional hand-tuned controls before exploring evolutionary optimization equations:
1. How do biological systems differ fundamentally from traditional engineered robotic systems in handling control?
Answer: Biological systems adapt through experience and evolutionary processes without exact internal models, whereas traditional systems rely on hand-tuned parameters and analytically derived mathematical models.
2. When does evolutionary and adaptive robotics become especially valuable for engineering design?
Answer: When analytical modeling becomes mathematically intractable due to nonlinear parameter coupling, discontinuous contact mechanics, high-dimensional control spaces, or unpredictable environmental dynamics.
Glossary of Evolutionary & Adaptive Robotics
Key foundational concepts and mathematical definitions used across bio-inspired optimization and real-time adaptation:
Conceptual Overview of Evolutionary Robotics
Evolutionary robotics applies principles of biological natural selection to automate engineering synthesis. Instead of relying on deterministic gradient descent or manual gain scheduling, algorithms maintain a population of candidate controllers that undergo simulated natural selection, stochastic mutation, and crossover recombination.
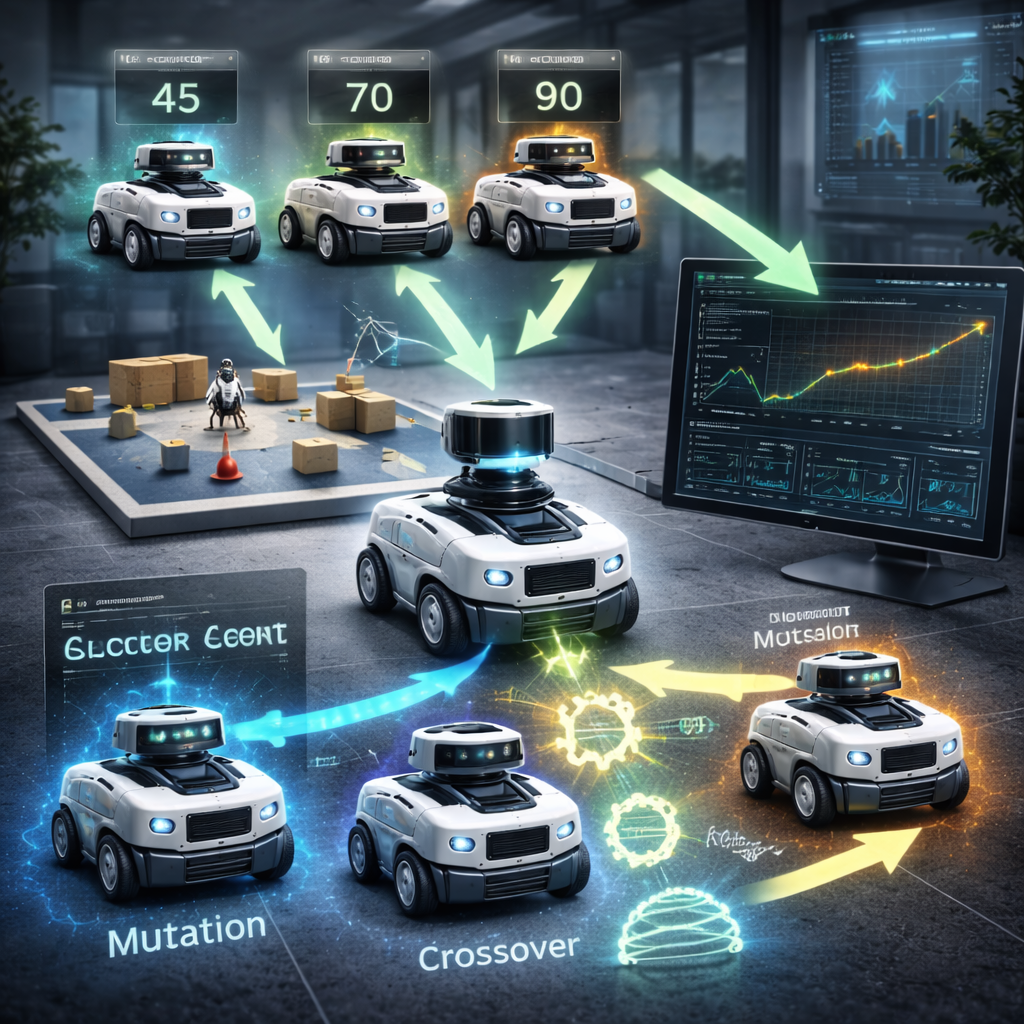
This illustration depicts how evolutionary robotics algorithms navigate high-dimensional parameter spaces. Candidate controllers are evaluated inside an obstacle arena, graded using an explicit fitness function, and iteratively combined. Over successive generations, the population discovers resilient behaviors that resolve complex contact dynamics without requiring hand-coded trajectory models.
Genetic Algorithms and Selection Mechanics
Genetic algorithms represent candidate robotic solutions as vectors or chromosomes \(\mathbf{x} \in \mathbb{R}^d\). If \(f(\mathbf{x})\) denotes the scalar fitness measuring mission success, the global optimization objective is:
$$\max_{\mathbf{x}} f(\mathbf{x})$$In standard fitness-proportionate selection (roulette-wheel selection), the probability \(P_i\) that candidate controller \(i\) is chosen to parent the next generation is:
$$P_i = \frac{f_i}{\sum_{j=1}^N f_j}$$Where \(f_i > 0\) is the fitness of candidate \(i\) across a population of size \(N\). Genetic diversity is maintained by injecting zero-mean Gaussian mutation noise into the parameter chromosome:
$$\mathbf{x}_{\text{new}} = \mathbf{x}_{\text{old}} + \boldsymbol{\epsilon}, \quad \boldsymbol{\epsilon} \sim \mathcal{N}(\mathbf{0}, \sigma^2 \mathbf{I})$$Consider a population of three candidate robotic navigation controllers evaluated in an obstacle track. Their measured performance fitness scores are \(f_1 = 10.0\), \(f_2 = 20.0\), and \(f_3 = 30.0\). Calculate the total population fitness and the exact selection probability for each candidate.
Encoding Robotic Parameters and Morphological Evolution
Robotic controllers can encode diverse behavioral and structural variables into continuous real-valued chromosomes:
- Feedback Gains: Proportional, integral, and derivative gains \([K_P, K_I, K_D]\) for joint motor drives.
- Locomotion Gait Timers: Central Pattern Generator (CPG) phase offsets, frequencies, and duty cycles for multi-legged robots.
- Morphological Dimensions: Mechanical link lengths, spring compliance constants, and actuator mounting locations.
For a robotic manipulator joint governed by a classical PID control law:
$$u(t) = K_P e(t) + K_I \int_0^t e(\tau) d\tau + K_D \dot{e}(t)$$The chromosome is represented as the gain vector \(\mathbf{x} = \begin{bmatrix} K_P & K_I & K_D \end{bmatrix}^T\). Applying crossover between two parent gain vectors \(\mathbf{x}_1\) and \(\mathbf{x}_2\) via blend interpolation (\(\alpha \in [0, 1]\)) yields:
$$\mathbf{x}_{\text{child}} = \alpha \mathbf{x}_1 + (1 - \alpha)\mathbf{x}_2$$An initial joint controller chromosome is defined as \(\mathbf{x}_{\text{old}} = \begin{bmatrix} 2.00 & 0.50 & 0.10 \end{bmatrix}^T\). A stochastic Gaussian mutation vector \(\boldsymbol{\epsilon} = \begin{bmatrix} 0.20 & -0.10 & 0.05 \end{bmatrix}^T\) is applied. Calculate the new mutated controller parameter vector and its Euclidean norm.
Evolutionary & Adaptive Robotics Challenges and Solutions
Deploying bio-inspired search and online adaptation to physical machines involves non-convexity, hardware degradation, and simulation modeling errors. Below are four key engineering bottlenecks and their technical mitigation frameworks:
The Challenge: Controllers optimized in simulated environments frequently fail when transferred to physical robots. Evolutionary algorithms exploit physics simulator approximations (such as contact spring stiffness, instantaneous gear engagement, or simplified friction), discovering behaviors that work in simulation but produce hardware damage in reality.
- Domain Randomization (DR): Randomizing simulator mass distributions, link inertias, joint friction, and sensor latency across every evaluation episode to force evolution toward robust policies.
- Envelope of Noise Architecture: Adding calibrated stochastic noise to sensor observations and actuator commands, ensuring that candidate policies do not rely on razor-thin deterministic simulation dynamics.
- Differentiable Physics Simulation: Integrating high-fidelity analytical contact models and real hardware logging to systematically align simulation parameters with physical ground truth.
The Challenge: Evolutionary algorithms require evaluating thousands of candidates across hundreds of generations. Direct physical on-hardware testing is bounded by battery runtimes, mechanical gear wear, and the risk of destructive collisions during early exploratory generations.
- Quality-Diversity (QD) Algorithms (e.g., MAP-Elites): Illuminating high-performing solutions across diverse behavioral feature spaces, maintaining repertoires of diverse behaviors rather than optimizing for a single fragile policy.
- Surrogate Modeling via Gaussian Processes: Employing data-efficient Bayesian optimization to approximate the fitness landscape, evaluating only the most informative candidate controllers on hardware.
- Parallel Distributed Physics Clusters: Running massive GPU-accelerated simulators (e.g., Isaac Gym, MuJoCo) to evaluate tens of thousands of candidate robots concurrently in seconds.
The Challenge: Genetic search optimizes strictly for the numerical score defined in the objective function. If a walking robot's fitness rewards forward center-of-mass velocity without penalizing impact shocks, algorithms evolve erratic falling behaviors rather than sustainable walking gaits.
- Multi-Objective Pareto Optimization (NSGA-II): Simultaneously optimizing task performance, energy expenditure, joint torque limits, and smooth jerk metrics across non-dominated Pareto fronts.
- Novelty Search and Behavioral Stepping Stones: Decoupling exploration from the objective reward by rewarding novel behaviors, allowing robots to discover intermediate coordination steps without falling into local minima traps.
- Minimal Criterion Co-Evolution: Establishing survivability thresholds where candidates must satisfy physical safety bounds (e.g., thermal limits, maximum tilt angles) before receiving performance grades.
The Challenge: In online adaptive control, aggressive adaptation gains combined with unmodeled high-frequency structural resonances or persistent external sensor noise cause parameter estimates to drift toward infinity, triggering physical instability.
- Projection Algorithms: Restricting adaptive parameters \(\hat{\boldsymbol{\theta}}(t)\) strictly within mathematically certified convex bounds \([\boldsymbol{\theta}_{\min}, \boldsymbol{\theta}_{\max}]\) that guarantee hardware safety.
- Dead-Zone Modifications: Halting online parameter updates whenever the tracking error falls within ambient sensor noise floors (\(\|e\| \le \epsilon_{\text{noise}}\)), eliminating noise-induced drift.
- \(\sigma\)-Modification (Leakage Terms): Augmenting the adaptation update law with a dissipative decay term (\(\dot{\hat{\boldsymbol{\theta}}} = \gamma e x - \sigma \hat{\boldsymbol{\theta}}\)) that pulls parameters toward a safe nominal baseline during signal dropouts.
Neuroevolution of Robotic Policies
Neuroevolution optimizes neural network policy parameters \(\boldsymbol{\theta}\) without calculating backpropagation gradients. Let a neural policy \(\pi_{\boldsymbol{\theta}}(\mathbf{s})\) map state vector \(\mathbf{s} \in \mathcal{S}\) to action vector \(\mathbf{a} \in \mathcal{A}\). The evolutionary objective optimizes expected cumulative return:
$$\max_{\boldsymbol{\theta}} \mathbb{E}_{\mathbf{s} \sim \mathcal{D}} [R(\boldsymbol{\theta})]$$Where \(R(\boldsymbol{\theta})\) is the cumulative episodic reward. Advanced methods such as Natural Evolution Strategies (NES) and Covariance Matrix Adaptation Evolution Strategy (CMA-ES) evaluate parameter distributions to compute pseudo-gradients across non-differentiable physics simulators:
$$\nabla_{\boldsymbol{\theta}} \mathbb{E}[R] \approx \frac{1}{\lambda \sigma} \sum_{i=1}^\lambda R_i \boldsymbol{\epsilon}_i, \quad \boldsymbol{\epsilon}_i \sim \mathcal{N}(\mathbf{0}, \mathbf{I})$$Real-Time Online Adaptive Control
While evolutionary algorithms search for optimal baseline parameters across generations, adaptive control modifies parameter estimates \(\hat{\boldsymbol{\theta}}(t)\) continuously during operation to compensate for unknown payload changes, thermal motor resistance, or component wear.
Let \(e(t) = y_d(t) - y(t)\) denote output tracking error and \(\mathbf{x}(t)\) be the system regressor vector. A standard Lyapunov-stable gradient adaptation law is formulated as:
$$\dot{\hat{\boldsymbol{\theta}}}(t) = \gamma \cdot e(t) \cdot \mathbf{x}(t)$$- \(\hat{\boldsymbol{\theta}}(t)\): Vector of online estimated parameters (e.g., payload mass, joint friction).
- \(\gamma > 0\): Adaptation gain determining the convergence learning rate.
- \(\mathbf{x}(t)\): Regressor vector containing known kinematic states and reference trajectories.
🎯 Career Guidance Tool Is Evolutionary & Adaptive Robotics Right For You?Explore bio-inspired artificial intelligence, self-learning robot design, and adaptive control engineering career pathways. | Explore Career Options → |
Interactive Quick Review: Genetic Algorithms, Neuroevolution & Adaptation
Reinforce key concepts regarding fitness selection, neuroevolution policies, and real-time adaptation before reviewing the FAQ:
1. How do genetic algorithms select candidate solutions for reproduction from a population?
Answer: By assigning selection probabilities proportional to each individual's task performance score evaluated via a fitness function (\(P_i = f_i / \sum_j f_j\)).
2. What is the fundamental difference between evolutionary search and real-time adaptive control?
Answer: Evolutionary search optimizes populations across generations (often offline in simulation), whereas adaptive control modifies parameter estimates continuously in real time during live hardware execution (\(\dot{\hat{\boldsymbol{\theta}}} = \gamma e \mathbf{x}\)).
External References and Further Reading
To explore advanced research, evolutionary algorithms, and biological computation in robotics, consult the following authoritative sources:
- MIT Press - Evolutionary Robotics – Foundational textbook covering automated robot design, evolutionary algorithms, and embodied autonomous intelligence.
- IEEE Transactions on Evolutionary Computation – Publishes peer-reviewed research papers covering genetic programming, evolutionary policy search, and multi-objective optimization.
- Nature Research - Evolutionary Robotics Collection – Features research exploring self-assembling modular robots, soft robotics evolution, and bio-inspired adaptive learning.
Frequently Asked Questions about Evolutionary and Adaptive Robotics
What is evolutionary robotics, and how does it differ from traditional programming?
Evolutionary robotics uses bio-inspired stochastic optimization algorithms to automatically discover robot control architectures and body morphologies. Instead of engineers manually deriving explicit differential kinematic equations and tuning gains, evolutionary algorithms search through high-dimensional parameter spaces to find behaviors that maximize high-level objective fitness functions.
How do genetic algorithms optimize robotic controller parameters like PID gains?
Parameters such as \(K_P\), \(K_I\), and \(K_D\) are encoded into chromosomes. A population of candidate gains is deployed in simulation or on hardware, evaluated on integrated tracking error, and subjected to fitness selection, blend crossover, and Gaussian mutation until optimal dynamic response characteristics emerge.
What is the "sim-to-real gap," and why is it a major challenge in evolutionary robotics?
The sim-to-real gap refers to discrepancies between simulated physics models and real-world physical dynamics. Controllers that discover behaviors exploiting simulation approximations (such as idealized friction or instantaneous motor torque) often fail or become unstable when transferred onto physical hardware, necessitating techniques like domain randomization.
How does neuroevolution combine neural networks with evolutionary search?
Neuroevolution optimizes neural network synaptic weights and layer topologies using evolutionary strategies (such as CMA-ES or NEAT) rather than gradient backpropagation. This allows robots to learn behaviors in sparse reward environments or through non-differentiable physics simulators where analytical gradients are unavailable.
End-of-Page Exercises: Review, Thought-Provoking & Engineering Problems
Section 1: Foundational Review Questions & Answers
1. What is the fundamental philosophical shift of evolutionary robotics compared to traditional hand-tuned control design?
Answer: Instead of prescribing exact behaviors or analytical models manually, engineers define high-level fitness performance objectives and allow structured search algorithms to discover effective solutions.
2. What biological evolutionary processes are simulated in genetic algorithms?
Answer: Natural selection, stochastic mutation, and recombination (crossover) operating across populations of candidate chromosome solutions.
3. How is the reproduction selection probability (\(P_i\)) calculated for an individual candidate solution in a genetic algorithm?
Answer: As the ratio of its individual fitness score to the cumulative sum of fitness scores across all candidates in the population (\(P_i = f_i / \sum_j f_j\)).
4. What types of robotic parameters can be encoded into chromosomes for evolutionary optimization?
Answer: Joint PID feedback gains, artificial neural network synaptic weights, link lengths, structural spring compliances, and CPG locomotion timing parameters.
5. What does a fitness landscape represent in evolutionary robotics optimization?
Answer: A geometric mapping from the high-dimensional parameter space of candidate controllers to their corresponding scalar task performance scores.
6. What is neuroevolution, and when is it most advantageous?
Answer: Neuroevolution optimizes neural networks using evolutionary algorithms, proving most advantageous when objective reward signals are non-differentiable, sparse, or unstable.
7. How does real-time adaptive control differ fundamentally from evolutionary search?
Answer: Adaptive control modifies parameter estimates continuously online during live machine deployment, whereas evolutionary search optimizes populations across offline generations.
8. What is the "sim-to-real gap" in robotics engineering?
Answer: The behavioral discrepancy that occurs when controllers evolved within idealized computer simulations fail or degrade upon transfer to physical robot hardware.
9. What adaptation law governs standard online parameter updates in adaptive control systems?
Answer: The gradient rule \(\dot{\hat{\boldsymbol{\theta}}} = \gamma e \mathbf{x}\), driven by tracking error \(e\), regressor signal vector \(\mathbf{x}\), and adaptation gain \(\gamma\).
10. What are the key engineering trade-offs when balancing evolutionary algorithm hyperparameters?
Answer: Exploration versus convergence speed, genetic diversity versus solution stability, computational evaluation cost versus solution quality, and simulation fidelity versus hardware transfer risk.
Section 2: Analytical & Thought-Provoking Questions
1. How can evolutionary algorithms exploit simulation flaws rather than solving the intended task?
Answer: Algorithms maximize numerical scores without human intent. If a walking robot's fitness rewards forward displacement without penalizing contact forces, the algorithm will evolve unrealistic tumbling or glitching behaviors that exploit physics integrator errors.
2. What limits direct on-hardware evolution of physical robots compared to simulated evolution?
Answer: Physical hardware suffers from battery exhaustion, mechanical actuator wear, real-time evaluation speed limits (hours per test), and catastrophic structural breakage during early exploratory generations.
3. How do rugged fitness landscapes trap gradient-free evolutionary searches?
Answer: While mutation can leap across fitness valleys, highly non-convex, rugged spaces can isolate populations in local suboptimal plateaus where random isotropic perturbations fail to find an ascending gradient.
4. What ethical and safety implications arise when robots evolve decision policies without human oversight?
Answer: Black-box evolved neural networks can produce emergent, unconstrained edge-case actions that violate safety boundaries, making safety verification, deterministic guarantees, and legal accountability difficult.
5. How does co-evolution alter optimization landscape dynamics?
Answer: Co-evolution creates dynamic, non-stationary fitness landscapes where competing or cooperating agents alter each other's fitness criteria, driving evolutionary arms races but risking cyclical behaviors.
6. What distinguishes biological evolution from engineering fitness optimization?
Answer: Biological evolution has no terminal engineering objective, selecting purely for survival and reproduction within shifting niches, whereas engineering optimization is guided toward human-specified target objectives.
7. How can modular soft robotics benefit from morphometric evolution?
Answer: Co-evolving body compliance, pneumatic chamber layouts, and neural activations allows the robot's physical structure to perform passive mechanical computations that simplify controller design.
8. What computational challenges emerge when scaling neuroevolution across distributed cloud clusters?
Answer: Coordinating parallel worker nodes requires synchronizing large neural weight vectors, balancing workload across heterogeneous GPUs, and managing cluster communication latency.
9. How do novelty search algorithms bypass deceptive fitness landscapes?
Answer: Novelty search rewards behavioral divergence from previous generations rather than task progress, preventing algorithms from becoming trapped in deceptive local optima.
10. What limitations affect online adaptive control when unmodeled structural resonances are present?
Answer: High adaptation gains (\(\gamma\)) excite high-frequency structural resonances, causing parameter estimates to drift and introducing destructive mechanical chatter.
11. How can transfer learning bridge the sim-to-real gap in evolutionary robotics?
Answer: By evolving generalized locomotion repertoires in simulation and using fast online adaptation or residual reinforcement learning to fine-tune policies on hardware.
12. What role do stochastic noise models play in preventing simulation overfitting?
Answer: Injecting randomized noise into sensor readings, actuator delays, and ground friction prevents controllers from memorizing specific simulation dynamics, fostering real-world transferability.
Section 3: Numerical Engineering Problems & Solutions
A population of four candidate robotic controllers yields fitness scores: \(f_1 = 15.0\), \(f_2 = 25.0\), \(f_3 = 35.0\), and \(f_4 = 25.0\). Calculate the total population fitness and determine the exact reproduction selection probability (\(P_i\)) for each individual controller.
Sum total fitness: $$\sum_{j=1}^4 f_j = 15.0 + 25.0 + 35.0 + 25.0 = 100.0$$ Compute selection probabilities: $$P_1 = \frac{15.0}{100.0} = 0.150 \quad (15.0\%)$$ $$P_2 = \frac{25.0}{100.0} = 0.250 \quad (25.0\%)$$ $$P_3 = \frac{35.0}{100.0} = 0.350 \quad (35.0\%)$$ $$P_4 = \frac{25.0}{100.0} = 0.250 \quad (25.0\%)$$ Final Answer: Total fitness is \(100.0\), with probabilities \(P_1 = 0.15\), \(P_2 = 0.25\), \(P_3 = 0.35\), and \(P_4 = 0.25\).
A robotic joint parameter chromosome is encoded as \(\mathbf{x}_{\text{old}} = \begin{bmatrix} 3.50 & 1.20 & 0.40 \end{bmatrix}^T\). During reproduction, a Gaussian mutation vector \(\boldsymbol{\epsilon} = \begin{bmatrix} 0.15 & -0.05 & 0.08 \end{bmatrix}^T\) is applied. Calculate the new mutated parameter vector \(\mathbf{x}_{\text{new}}\).
Mutation equation: $$\mathbf{x}_{\text{new}} = \mathbf{x}_{\text{old}} + \boldsymbol{\epsilon}$$ Element-wise evaluation: $$x_1 = 3.50 + 0.15 = 3.65$$ $$x_2 = 1.20 + (-0.05) = 1.15$$ $$x_3 = 0.40 + 0.08 = 0.48$$ Final Answer: Mutated parameter vector is \(\begin{bmatrix} 3.65 & 1.15 & 0.48 \end{bmatrix}^T\).
An evolutionary robotics experiment tracks the reward \(R\) of elite control policies across generations. In Generation 1, elite reward is \(R_1 = 30.0\). By Generation 20, elite reward reaches \(R_{20} = 75.0\). Calculate the absolute reward gain and the percentage improvement.
Absolute reward gain: $$\Delta R = R_{20} - R_1 = 75.0 - 30.0 = 45.0$$ Percentage improvement: $$\% \text{ Gain} = \left(\frac{R_{20} - R_1}{R_1}\right) \times 100 = \left(\frac{45.0}{30.0}\right) \times 100 = 1.50 \times 100 = 150.0\%$$ Final Answer: Absolute gain is \(45.0\), representing a \(150.0\%\) performance improvement.
An online adaptive control system operates with adaptation gain \(\gamma = 0.50\). At a given sampling instant, tracking error is measured as \(e = 0.12\text{ rad}\), and the regressor signal value is \(x = 1.50\). Calculate the instantaneous parameter rate of change \(\dot{\hat{\theta}}\).
Gradient adaptive update law: $$\dot{\hat{\theta}} = \gamma \cdot e \cdot x$$ Substitute values: $$\dot{\hat{\theta}} = 0.50 \times 0.12 \times 1.50 = 0.50 \times 0.18 = 0.090\text{ s}^{-1}$$ Final Answer: Instantaneous parameter adaptation rate is \(\dot{\hat{\theta}} = 0.090\).
A generation of 5 evolved crawler robot controllers records distance traversal fitness scores: \([12.5, 18.0, 9.5, 22.0, 15.0]\). Calculate the population mean fitness \(\mu_f\) and identify the maximum fitness score.
Sum total fitness: $$\sum f_i = 12.5 + 18.0 + 9.5 + 22.0 + 15.0 = 77.0$$ Compute mean fitness: $$\mu_f = \frac{77.0}{5} = 15.40$$ Maximum score: $$f_{\max} = \max([12.5, 18.0, 9.5, 22.0, 15.0]) = 22.0$$ Final Answer: Population mean fitness is \(15.40\); maximum fitness is \(22.0\).
Two parent robot controllers are represented by parameter vectors \(\mathbf{x}_1 = \begin{bmatrix} 2.0 & 4.0 & 6.0 \end{bmatrix}^T\) and \(\mathbf{x}_2 = \begin{bmatrix} 4.0 & 2.0 & 8.0 \end{bmatrix}^T\). Applying a linear blend crossover operator with interpolation weight \(\alpha = 0.40\), calculate the child parameter vector \(\mathbf{x}_{\text{child}} = \alpha \mathbf{x}_1 + (1 - \alpha)\mathbf{x}_2\).
Blend crossover formula: $$\mathbf{x}_{\text{child}} = 0.40 \mathbf{x}_1 + 0.60 \mathbf{x}_2$$ Compute elements: $$x_{\text{child}, 1} = 0.40(2.0) + 0.60(4.0) = 0.80 + 2.40 = 3.20$$ $$x_{\text{child}, 2} = 0.40(4.0) + 0.60(2.0) = 1.60 + 1.20 = 2.80$$ $$x_{\text{child}, 3} = 0.40(6.0) + 0.60(8.0) = 2.40 + 4.80 = 7.20$$ Final Answer: Resulting child parameter vector is \(\begin{bmatrix} 3.20 & 2.80 & 7.20 \end{bmatrix}^T\).
Evaluating a population of 100 candidate controllers physically on hardware requires \(T_{\text{hardware}} = 50.0\text{ hours}\) per generation. By evaluating the population inside a parallel physics simulator, execution time drops to \(T_{\text{sim}} = 15.0\text{ minutes}\) (\(0.25\text{ hours}\)). Calculate the simulation acceleration speedup factor.
Speedup factor formula: $$\text{Speedup} = \frac{T_{\text{hardware}}}{T_{\text{sim}}}$$ Substitute values: $$\text{Speedup} = \frac{50.0\text{ hours}}{0.25\text{ hours}} = 200.0$$ Final Answer: Simulation acceleration achieves a \(200.0\times\) speedup factor.
A genetic algorithm optimizes a PID motor controller gain chromosome encoded as vector \(\mathbf{x} = \begin{bmatrix} K_P & K_I & K_D \end{bmatrix}^T = \begin{bmatrix} 12.50 & 1.80 & 0.45 \end{bmatrix}^T\). Calculate the Euclidean norm (magnitude) of the parameter chromosome vector.
Euclidean norm formula: $$\|\mathbf{x}\| = \sqrt{K_P^2 + K_I^2 + K_D^2}$$ Square individual terms: $$(12.50)^2 = 156.25, \quad (1.80)^2 = 3.24, \quad (0.45)^2 = 0.2025$$ Sum and take square root: $$\|\mathbf{x}\| = \sqrt{156.25 + 3.24 + 0.2025} = \sqrt{159.6925} \approx 12.63695$$ Final Answer: Euclidean norm of the gain chromosome is approximately \(12.64\).
An automated evolutionary loop executes for \(G = 500\text{ generations}\). Each generation evaluates a population of \(M = 250\text{ candidate individuals}\), with each test episode running for \(T_{\text{episode}} = 4.0\text{ seconds}\) in simulation. Calculate the total cumulative simulation testing time in hours.
Total evaluation episodes: $$N_{\text{total}} = 500 \times 250 = 125{,}000\text{ episodes}$$ Total simulation seconds: $$T_{\text{sec}} = 125{,}000 \times 4.0\text{ s} = 500{,}000\text{ seconds}$$ Convert to hours (\(3{,}600\text{ s/h}\)): $$T_{\text{hours}} = \frac{500{,}000\text{ s}}{3{,}600\text{ s/h}} \approx 138.889\text{ hours}$$ Final Answer: Cumulative simulation time is approximately \(138.89\text{ hours}\) (\(\approx 5.79\text{ days}\) of sequential compute).
A neuroevolution controller policy has a parameter mutation variance of \(\sigma^2 = 0.040\) for its Gaussian mutation operator. Calculate the standard deviation \(\sigma\) used to scale stochastic noise perturbations.
Standard deviation formula: $$\sigma = \sqrt{\sigma^2}$$ Substitute numerical value: $$\sigma = \sqrt{0.040} = 0.20$$ Final Answer: Mutation scaling standard deviation is \(\sigma = 0.20\).
A decentralized swarm coordination rule is evolved. A baseline hand-tuned rule achieves an average foraging efficiency of \(E_{\text{base}} = 42.0\%\), while the evolved swarm rule achieves \(E_{\text{evolved}} = 68.0\%\). Calculate the absolute percentage point increase and relative performance gain.
Absolute increase: $$\Delta E = 68.0\% - 42.0\% = 26.0\text{ percentage points}$$ Relative performance gain: $$\% \text{ Gain} = \left(\frac{68.0 - 42.0}{42.0}\right) \times 100 = \left(\frac{26.0}{42.0}\right) \times 100 \approx 61.905\%$$ Final Answer: Absolute increase is \(26.0\text{ percentage points}\), representing a \(61.90\%\) relative gain.
An adaptive tracking controller produces exponential error decay governed by \(e(t) = e_0 e^{-\lambda t}\). If the initial tracking error is \(e_0 = 0.80\text{ meters}\) and the adaptation convergence rate is \(\lambda = 2.0\text{ s}^{-1}\), calculate the tracking error magnitude after elapsed time \(t = 1.0\text{ second}\). (Use \(e^{-2.0} \approx 0.135335\)).
Exponential decay formula: $$e(1.0) = 0.80 \times e^{-(2.0 \times 1.0)} = 0.80 \times e^{-2.0}$$ Substitute numerical value: $$e(1.0) = 0.80 \times 0.135335 \approx 0.108268\text{ meters}$$ Final Answer: Tracking error after \(1.0\text{ second}\) is approximately \(0.11\text{ meters}\).
Evolutionary and Adaptive Robotics — Summary & Wrap-Up
Evolutionary and adaptive robotics bridge biology-inspired computation and intelligent engineering control, replacing rigid hand-tuned models with automated search, selection, and real-time adaptation. By mastering genetic algorithms, chromosome parameter encoding, fitness landscapes, neuroevolution, and online adaptive laws, robotics engineers unlock resilient autonomous machines capable of learning, evolving, and optimizing complex behaviors in unstructured real-world environments.
Intelligence and Decision Systems Across the Robotics Ecosystem
Evolutionary and adaptive robotics represent a fundamental shift in how machines acquire intelligent behavior, moving away from explicit manual programming toward automated optimization, learning, and self-adjustment. These principles form a core pillar of the broader intelligence and decision systems that govern modern autonomous platforms.
Many optimization and policy-search techniques developed in evolutionary robotics are closely related to methods studied in Reinforcement Learning for Robot Control, where trial-and-error interaction and reward maximization guide continuous controller improvement. Similarly, decentralized rule discovery connects directly with Swarm and Multi-Agent Robotics, enabling large fleets of autonomous agents to coordinate complex group behaviors.
The computational frameworks that support intelligence and decision-making depend heavily on underlying software and hardware infrastructure. Distributed task allocation and collective model sharing rely on concepts from Cloud Robotics and Edge Intelligence, while real-time execution of adaptive control laws requires deterministic scheduling supported by Real-Time Embedded Systems in Robotics.
Furthermore, the physical realization of evolved controllers relies on robust hardware design. Morphological optimization connects directly with Mechanical Design and CAD Engineering, ensuring that evolved parameter sets translate successfully from simulation into physical machine structures.
Readers interested in exploring the broader interdisciplinary landscape of intelligent machines—ranging from perception and planning to human-robot interaction—can visit the Robotics Hub, which provides a comprehensive gateway into modern applied robotics.