The Mathematics of 3D Printing Slicing
STL Geometry, Ray-Casting & Toolpath Slicing Foundations
Core Competencies Learned
- Calculate linear interpolation and intersection points for single triangular facets using vector equations.
- Evaluate point inclusion using ray-casting algorithms and Even-Odd parity logic for complex geometric slices.
- Understand the rasterization patterns and G-code coordinate generation required to translate continuous geometry into toolpaths.
To print a 3D digital object, software must first deconstruct it. Every additive manufacturing system works in layer-by-layer coordinates. Slicing translates a 3D boundary representation (B-Rep)—typically an STL (Stereolithography) mesh—into 2D paths a printhead or laser can trace. This module walks through the vector math, intersection proofs, and toolpath algorithms that govern this translation.
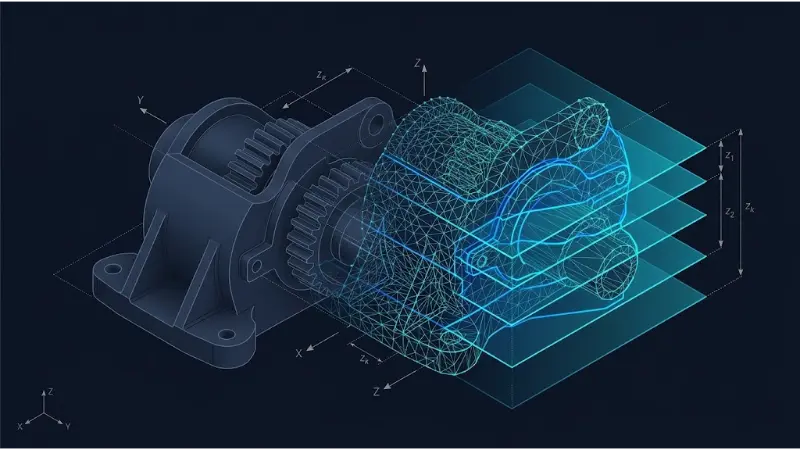
Figure 1: The slicing workflow. Solid CAD geometry is translated to a triangular STL wireframe, which is then intersected by parallel slicing planes at height \( z = z_k \).
Slicing Process Flow: Functional Architecture (IDEF0)
To analyze the slicing workflow as a systematic mathematical machine, we define its four functional boundaries:
1. Slicing Mathematics and Edge Intersection
An STL file represents a 3D surface using an unorganized collection of triangular facets. Each facet \( i \) is defined by three vertices, \( V_1(x_1, y_1, z_1) \), \( V_2(x_2, y_2, z_2) \), and \( V_3(x_3, y_3, z_3) \), alongside an outward unit normal vector \( \mathbf{n} = (n_x, n_y, n_z) \).
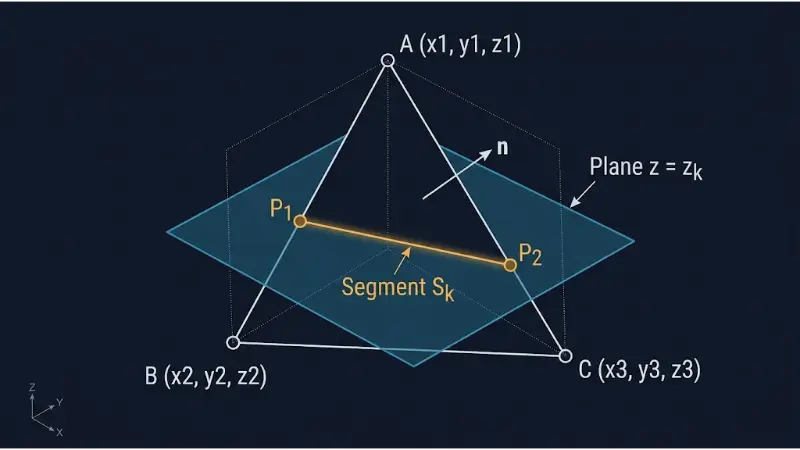
Figure 2: Geometry of a facet-plane intersection. Slicing plane \( z = z_k \) intersects the triangle's edges at points \( P_1 \) and \( P_2 \).
When slicing at a horizontal plane \( z = z_k \), we first determine if a triangle intersects the plane. An intersection only exists if \( z_k \) is between the facet's minimum and maximum z-coordinates:
$$ \min(z_1, z_2, z_3) \leq z_k \leq \max(z_1, z_2, z_3) $$To avoid degenerate edge cases (where the plane passes exactly through a vertex), we shift the plane by a tiny value \( \epsilon \approx 10^{-6}\text{ mm} \) if an exact match occurs.
For each intersected edge, we find the coordinate where the plane cuts it. Let an edge be defined by endpoints \( A(x_A, y_A, z_A) \) and \( B(x_B, y_B, z_B) \). We can represent any point \( P(x, y, z) \) on this edge using the parameter \( t \in [0, 1] \):
$$ P(t) = (1 - t)A + tB \quad \Rightarrow \quad z(t) = (1 - t)z_A + tz_B $$To find the intersection at \( z(t) = z_k \), we solve for \( t \):
$$ z_k = z_A + t(z_B - z_A) \quad \Rightarrow \quad t = \frac{z_k - z_A}{z_B - z_A} $$Because the intersection must lie between \( A \) and \( B \), \( t \) must fall in the interval \( (0, 1) \). Once we have \( t \), we calculate the 2D coordinates (\( x \), \( y \)) of the intersection:
$$ x_k = x_A + t(x_B - x_A), \quad y_k = y_A + t(y_B - y_A) $$Applying this calculation to the two intersected edges yields points \( P_1(x_{P1}, y_{P1}, z_k) \) and \( P_2(x_{P2}, y_{P2}, z_k) \). Together, these points form a 2D line segment \( S_k \) on the slicing plane. Collecting and connecting these segments for all intersected facets reconstructs the slice's 2D boundary.
Worked Example: Intersecting a Single Facet
Problem: Calculate the intersection of the triangle with vertices \( V_1(10, 10, 40) \), \( V_2(30, 10, 10) \), and \( V_3(20, 40, 20) \) and the slicing plane \( z_k = 25 \).
Step 1: Verify the intersection
The z-bounds are \( z_{min} = 10 \) and \( z_{max} = 40 \). Because \( z_k = 25 \) lies between 10 and 40, the facet intersects the plane.
Step 2: Find the intersected edges
- Edge 1 (\( V_1 \to V_2 \)): Span \( z_1 = 40 \to z_2 = 10 \). Contains \( z = 25 \).
- Edge 2 (\( V_1 \to V_3 \)): Span \( z_1 = 40 \to z_3 = 20 \). Contains \( z = 25 \).
- Edge 3 (\( V_2 \to V_3 \)): Span \( z_2 = 10 \to z_3 = 20 \). Does not reach \( z = 25 \).
Step 3: Calculate the intersection on Edge 1 (\( V_1 \to V_2 \))
$$ t_1 = \frac{z_k - z_1}{z_2 - z_1} = \frac{25 - 40}{10 - 40} = \frac{-15}{-30} = 0.5 $$ $$ x_{P1} = x_1 + t_1(x_2 - x_1) = 10 + 0.5(30 - 10) = 20 $$ $$ y_{P1} = y_1 + t_1(y_2 - y_1) = 10 + 0.5(10 - 10) = 10 $$ Point \( P_1 = (20, 10) \).Step 4: Calculate the intersection on Edge 2 (\( V_1 \to V_3 \))
$$ t_2 = \frac{z_k - z_1}{z_3 - z_1} = \frac{25 - 40}{20 - 40} = \frac{-15}{-20} = 0.75 $$ $$ x_{P2} = x_1 + t_2(x_3 - x_1) = 10 + 0.75(20 - 10) = 17.5 $$ $$ y_{P2} = y_1 + t_2(y_3 - y_1) = 10 + 0.75(40 - 10) = 32.5 $$ Point \( P_2 = (17.5, 32.5) \).2. Interior/Exterior Classification: The Ray-Casting Algorithm
To fill the intersected boundaries with solid patterns, the slicer must differentiate the interior from the exterior. It does this using the Ray-Casting Algorithm, which relies on the Even-Odd Parity Rule.
The algorithm shoots an imaginary horizontal ray from outside the print bed boundaries across the sliced cross-section. Slicers track every point where this ray intersects the boundary lines:
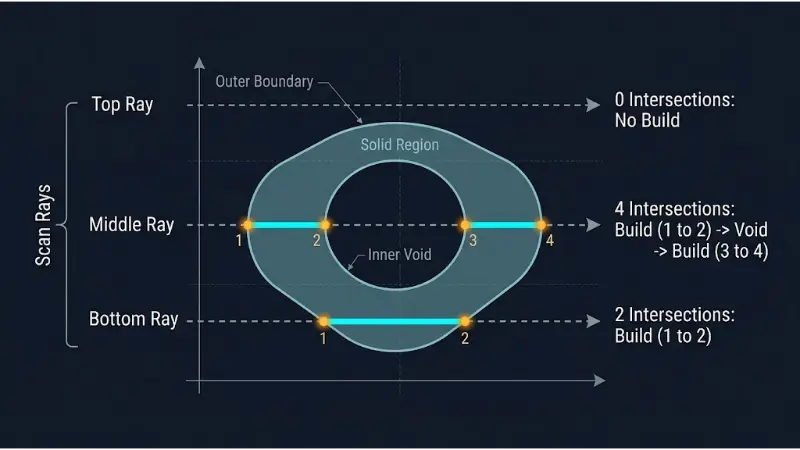
Figure 3: The Ray-Casting parity test. The middle ray has 4 intersections (crosses boundaries 1 and 2, exits back into space at 3, and terminates at 4).
For any point \( P_{test} \), we cast a horizontal ray \( R(t) = (x_{test} + t, y_{test}) \) for \( t \ge 0 \). We count how many times this ray intersects the polygon’s boundary edges. This count determines whether the point is inside the boundary:
- Even count of intersections: The point is Outside the shape.
- Odd count of intersections: The point is Inside the shape.
This simple logic allows the slicer to determine where to deposit material and where to avoid it (voids), ensuring proper boundary fills for any shape.
3. Rasterization & Toolpath Generation
Once the boundary is defined and the interior is identified, the slicer converts these areas into 2D motion paths. The toolpath is generally divided into two types: boundary perimeters and infill patterns.
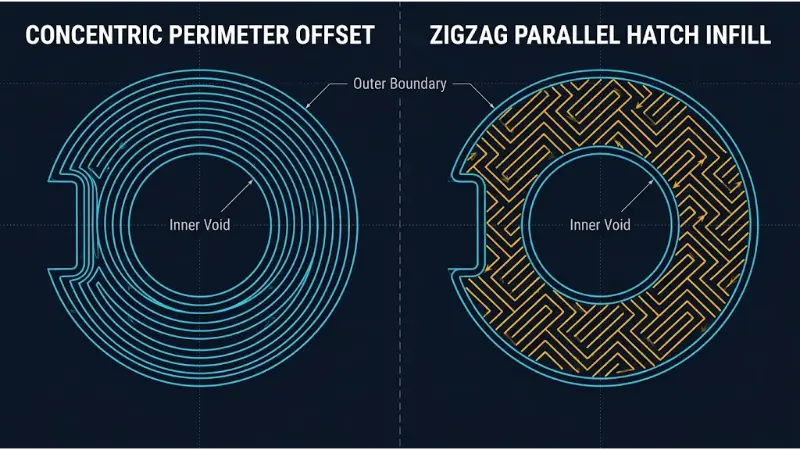
Figure 4: Toolpath generation comparison. The perimeter-only offset strategy (left) contrasted with a perimeter and zigzag hatch infill pattern (right).
Boundary Perimeters: The printhead traces the outer shape, offsetting inward by half the nozzle's width (\( W / 2 \)) to ensure accurate dimensions. This offset is computed by shifting the boundary vertices inward along their normal vectors.
Infill Rasterization: The solid areas inside the perimeters are filled using repeating geometric patterns. Slicers generate these paths by intersecting parallel line patterns with the boundary shapes, then trimming them to fit the interior using our ray-casting intersection math.
4. Interactive Slicing Mathematical Demonstration
Adjust the slicing parameters below to see how a horizontal plane (\(z_k\)) cuts through triangular facets and generates 2D segments in real time.
5. Trade-Off Analysis: Slicing Slices vs Speed/Accuracy
Additive parameters involve continuous compromises. Adjusting slice height or geometry alters mechanical reliability, finish quality, and print time:
| Slicing Setup Strategy | Primary Advantage | Key Technical Bottleneck | Optimization / Mitigation |
|---|---|---|---|
| Sub-0.1 mm Micro Slices | Excellent surface finish; reduced staircase effects on curves. | Extreme print times; increased risk of build failure due to cumulative errors. | Dynamic layer slicing; thinning layers only on curve sections. |
| Adaptive Dynamic Layering | Balances detail and speed by adjusting layer height based on local slope. | Complex toolpath transitions can lead to extrusion inconsistency. | Advanced firmware calibrations; adjusting material flow dynamically. |
| Concentric Outline Fills | High perimeter accuracy; minimizes tool vibration. | Poor interior filling; often creates internal gaps. | Hybrid infill; combining perimeters with internal zigzag paths. |
6. Slicing Mathematics and Algorithms FAQ
Q1: What are the primary mathematical limitations of the STL file format for slicing?
STL files represent 3D surfaces as unorganized collections of flat triangles. They lack topological connectivity data (which vertices connect to which edges), forcing the slicer to reconstruct edge loops from scratch. This can lead to degenerate edges, tiny gaps, and geometric errors that require intensive computational repair before slicing can occur.
Q2: How does a slicer handle degenerate triangles or broken meshes?
If an STL has small gaps, overlapping facets, or non-manifold edges, the slicing plane may generate open, incomplete loops instead of closed boundaries. Slicers attempt to fix these by stitching nearby endpoints together within a tiny tolerance (e.g., 0.001 mm) or using volumetric pixel grid (voxel) techniques to reconstruction the geometry.
Q3: Why is the Jordan Even-Odd rule used instead of other point-in-polygon tests?
The Even-Odd rule is computationally efficient and robust, particularly for meshes with complex internal voids. It is easy to implement using 2D ray searches because it only requires counting intersections along a ray, rather than computing winding numbers, which require complex angular calculations.
Q4: How do numerical rounding errors affect the generated slice geometry?
Rounding errors can cause intersection points on shared facet edges to mismatch slightly, breaking the continuity of boundary loops. Standard slicers prevent this by using high-precision floats (64-bit doubles) and merging points that fall within a tiny spatial threshold.
Q5: How does adaptive slicing calculate changing layer heights?
Adaptive slicing analyzes the local slope of the mesh's surface normal vectors relative to the build axis (Z-axis). If it detects steep slope changes or fine vertical curves, it decreases the slice step size to minimize staircase effects; on straight vertical sections, it increases the step size to speed up the print.
Q6: Why are boundary perimeters usually printed before infill patterns?
Printing perimeters first establishes a precise external border, which improves dimensional accuracy and supports internal material flow. If infill is printed first, it can cause the perimeters to bulge slightly, reducing surface finish quality and part tolerances.
7. Slicing Mathematics Self-Assessment
Tier 1: Foundational Practice (True/False & Concept Multiple Choice)
Q1.1: If a horizontal slicing plane z_k passes through a triangular facet, can it intersect only one edge?
Q1.2: A triangular facet has vertices with z-coordinates of 15.2, 10.4, and 30.1. Will it be intersected by slicing plane z_k = 15.0?
Q1.3: Under the Even-Odd Parity rule, if a test ray has 5 intersections with a slice boundary, is the origin point inside or outside?
Q1.4: True or False: STL files contain explicit mathematical descriptions of curves like holes and cylinders.
Q1.5: The parameter 't' in linear interpolation equations must be in what interval for valid on-edge intersections?
Q1.6: Why does slicing a tilted, curved part produce a rough staircase pattern?
Q1.7: When a test ray is exactly parallel to and touches a boundary edge, what issue does it create?
Q1.8: Why is checking minimum/maximum vertex z-height used as a preliminary filter before edge calculations?
Tier 2: Applied Conceptual Cases & Slicer Debugging
Q2.1: Analyzing the geometric results of open-loop errors
Analysis: Unfilled sections suggest an unclosed (open) boundary loop. Slicers can only apply the even-odd test to complete, closed loops. If a gap exists, the scan ray fails to return the expected even/odd patterns, causing the software to misclassify filled areas. You can fix this by repairing the STL to stitch broken edges or using the slicer's self-repair options to bridge small gaps.
Q2.2: Managing vertices located exactly on slicing planes
Analysis: Perfect alignment with vertices can result in ambiguous intersections (the plane touches a vertex, rather than cutting an edge), which disrupts the even-odd count. Slicers typically prevent this by applying a tiny shift to the cutting plane (e.g., \( z_k \pm 10^{-6}\text{ mm} \)) to ensure the plane only intersects actual edges, resolving the geometric ambiguity.
Q2.3: Calculating tool orientation offsets for tight holes
Analysis: Slicers shift toolpaths inward along surface normal vectors by the tool's radius (\( W / 2 \)) to compensate for extrusion width. On small holes, material can over-squeeze inward due to rapid curvature, reducing the printed opening. You can compensate for this by applying shrinkage factors, adjusting extrusion flow, or modifying the CAD design to use slightly larger hole tolerances.
Q2.4: Speed-accuracy tradeoffs in curved surfaces
Analysis: Fixed 0.2 mm layers produce a fast print, but leave rough staircase patterns on the top dome curves. Using 0.05 mm layers solves the staircase effect, but dramatically increases print times. An adaptive slicer solves this by varying the layer height—using thin layers on the dome's slopes to preserve detail, and thick layers on the vertical walls to keep print times fast.
Q2.5: The computational cost of mesh density
Analysis: Large STL files contain millions of triangles, many with dimensions smaller than the print nozzle's diameter. Intersecting, sorting, and linking this level of geometry strains memory and processor time. Simplify the mesh in CAD or reduce its triangle count prior to slicing to decrease the calculation burden without affecting the final print quality.
Q2.6: Choosing infill strategy based on tool travel time
Analysis: Concentric perimeters produce smooth, continuous paths that minimize decelerations, making them highly efficient for boundary printing. However, filling a large internal area concentrically can leave poor material connections at the center. Zigzag infill is easier to pattern and ensures consistent density, but requires the toolhead to stop and reverse direction frequently, which can increase travel times on large prints.
Q2.7: Overhang failures on un-supported slopes
Analysis: Slicing overhanging geometry causes each layer to shift outward, leaving part of the new extrusion unsupported in thin air. At angles past a critical limit (usually 45°), the lack of support causes gravity to pull the molten material downward before it can bond. Activating support structures or modifying the design to keep overhangs under 45° prevents these drooping failures.
Tier 3: Slicing Mathematics & Numerical Exercises
Q3.1: Finding linear intersection on an angled edge
Steps: 1. Calculate interpolation parameter \( t \): $$ t = \frac{z_k - z_1}{z_2 - z_1} = \frac{25 - 10}{40 - 10} = \frac{15}{30} = 0.5 $$ 2. Substitute \( t \) into coordinate equations: $$ x = x_1 + t(x_2 - x_1) = 0 + 0.5(20 - 0) = 10 $$ $$ y = y_1 + t(y_2 - y_1) = 0 + 0.5(10 - 0) = 5 $$
Q3.2: Calculating the interpolation ratio t for custom planes
Steps: Calculate for each height using the formula \( t = \frac{z_k - z_1}{z_2 - z_1} \), where \( z_2 - z_1 = 22.5 - 12.5 = 10.0 \): * For \(z_k = 15.0\): $$t = \frac{15.0 - 12.5}{10.0} = 0.25$$ * For \(z_k = 17.5\): $$t = \frac{17.5 - 12.5}{10.0} = 0.50$$ * For \(z_k = 20.0\): $$t = \frac{20.0 - 12.5}{10.0} = 0.75$$
Q3.3: Resolving degenerate coordinate vertex intersection
Steps: 1. Slicing plane aligns exactly with \(V_1\) (\(z = 25.0\)), creating a potential edgecase mismatch. 2. Set \(\epsilon = 10^{-6}\) to adjust \(z_k\) slightly below 25.0 to resolve the ambiguity: $$z_k' = z_k - \epsilon = 24.999999 \text{ mm}$$ The adjusted plane falls below 25.0, removing V1 as a plane intersection point and ensuring normal calculation on the two vertical edges without triggering degenerate software loops.
Q3.4: Finding coordinates on an angled edge
Steps: 1. Solve for interpolation parameter \(t\): $$t = \frac{18.0 - 12.0}{22.0 - 12.0} = \frac{6.0}{10.0} = 0.6$$ 2. Substitute \(t = 0.6\) into coordinates equations: $$x_{mid} = 5 + 0.6(15 - 5) = 5 + 6 = 11.0$$ $$y_{mid} = 8 + 0.6(20 - 8) = 8 + 7.2 = 15.2$$ The intersection coordinate is \((11.0, 15.2, 18.0)\).
Q3.5: Estimating G-code segments for outer outlines
Steps: Draft the ordered travel parameters based on standard machine G-code format: 1. Position the printhead without extruding (G0) to the starting intersection point:
G0 X15.0 Y20.0 Z15.0 F1800.02. Trace and extrude (G1) to the end intersection point:
G1 X35.0 Y40.0 E1.45
Q3.6: Estimating staircase errors on angled profiles
Steps: 1. Relationship for step width is defined by slope angle \(\theta\): $$\tan(\theta) = \frac{h}{\delta_x} \quad \implies \quad \delta_x = \frac{h}{\tan(\theta)}$$ 2. For \(h_1 = 0.2\text{ mm}\): $$\delta_x = \frac{0.2}{\tan(60^\circ)} = \frac{0.2}{1.732} = 0.1155\text{ mm}$$ 3. For \(h_2 = 0.05\text{ mm}\): $$\delta_x = \frac{0.05}{\tan(60^\circ)} = \frac{0.05}{1.732} = 0.0289\text{ mm}$$
Interactive Education Hub Navigation
Expand your knowledge by browsing other advanced resources in the Additive Manufacturing track:
Slicing Mathematics & Toolpaths
The definitive guide on translating unorganized 3D STL meshes into layer-by-layer motion paths and parity classifications.
Overhang Limit & Support Physics
Learn how shear limits and thermal transfer requirements dictate the placement and math of support structures.
The ISO/ASTM 52900 7 Categories
Analyze process characteristics and hardware mechanisms across all seven official ASTM AM process types.